Archive for the ‘Space News’ Category
 Author:
 May 10th, 2017
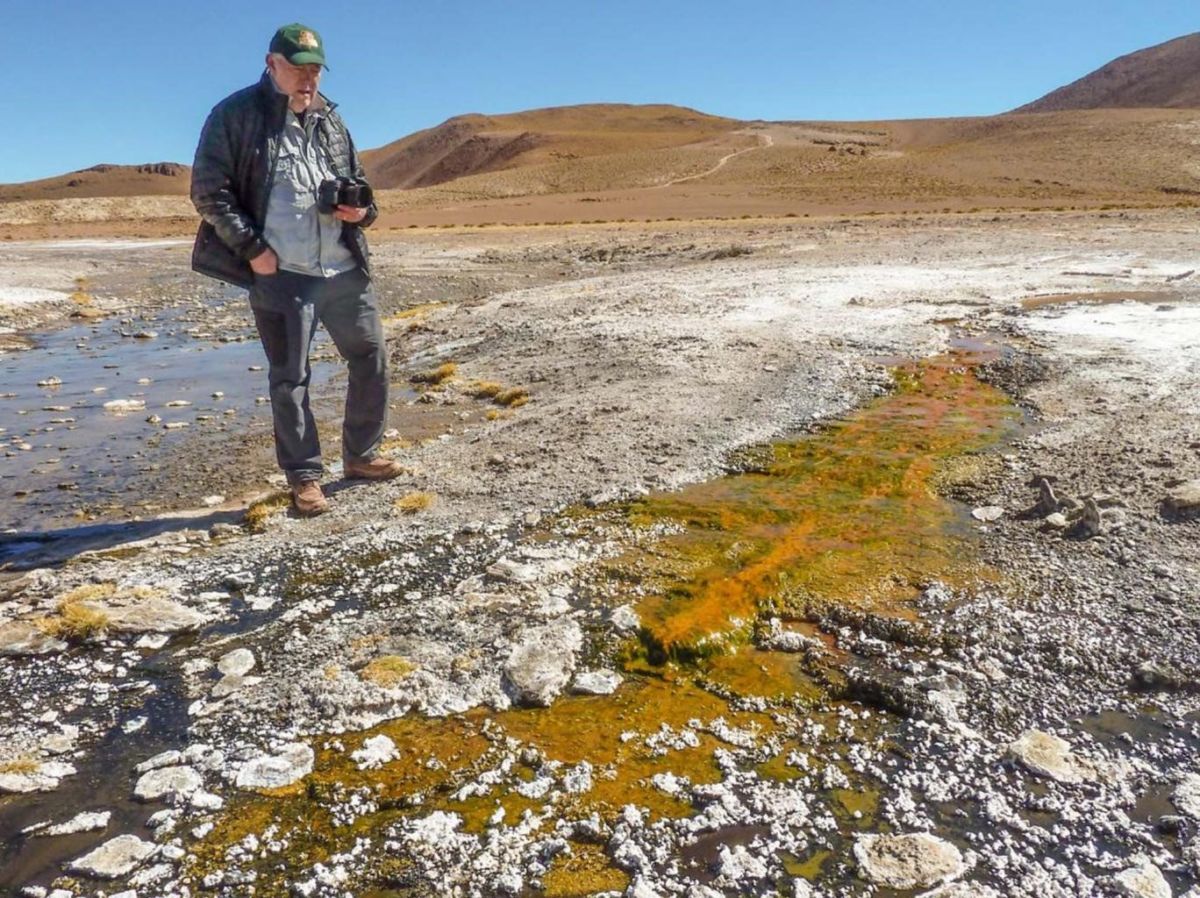
Arizona State University astrobiologist Jack Farmer studies an outflow colored by microorganisms that flows from the hot springs at El Tatio in Chile. The microorganisms appear nearly identical to silica structures found by the NASA Spirit rover at a site on Mars.
Credit: Steve Ruff
Billions of dollars have been spent in reconnoitering Mars since the 1960s. That world has been on the receiving end from Earth of robotic flybys, photo-snapping orbiters and numbers of nose-diving craft onto its surface.
Indeed, the Red Planet has been radar pinged, crashed into, soft landed upon, scooped up, digested and laser zapped, wheeled across and generally scuffed up.
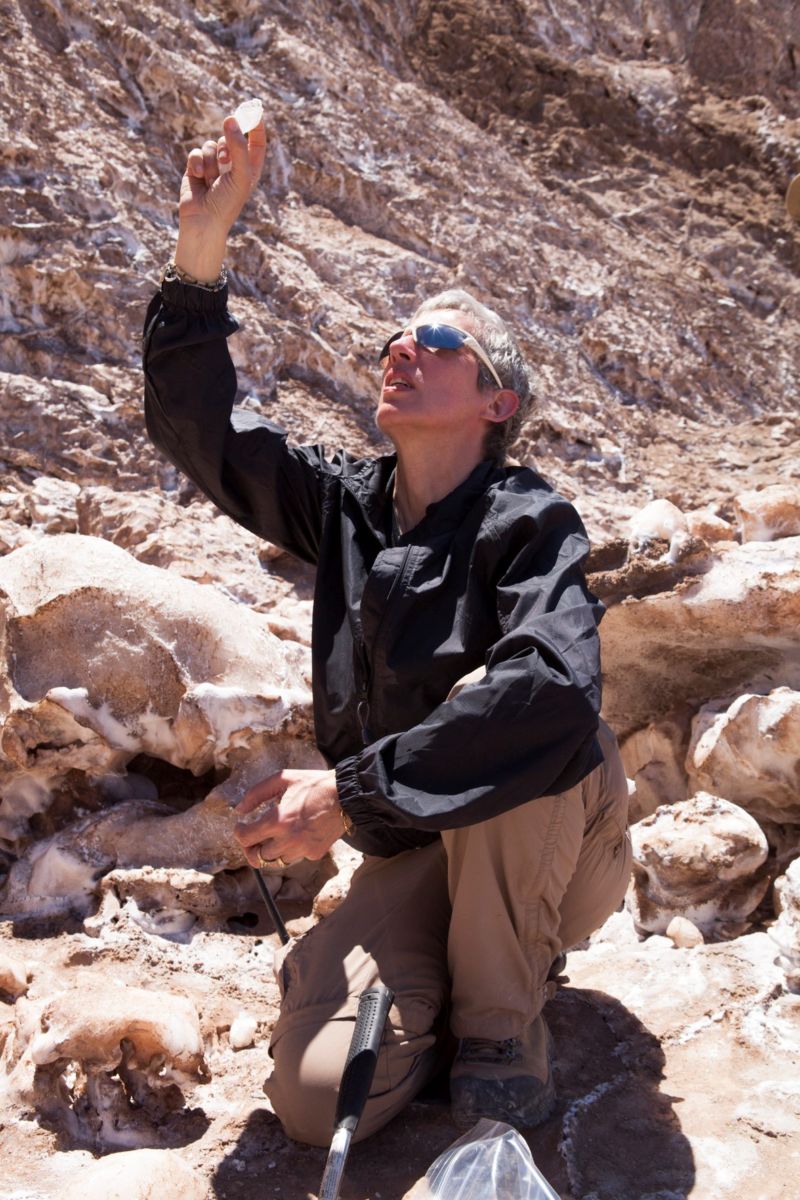
Nathalie Cabrol, Senior Research Scientist and Director of the Carl Sagan Center at the SETI Institute in Mountain View, California. Cabrol is shown here at Salar Grande, Atacama Desert, Chile in November 2016, looking for signs of microbial colonies in salt crystals.
Credit: Victor Robles, Campoalto/SETI Institute NAI Team 2016.
Poker-faced world
Decades later it remains a poker-faced world – with the house odds suggesting it could be an extraterrestrial address for life. If so, Mars is not giving up its secrets easily — or to stretch the metaphor more – holding its cards tight.
Scientists continue to, quite literally, chip away at finding the truth. Locating evidence of present-day life on that planet is viewed by Mars researchers as a watershed event but also a perplexing quest.
Take a look at my new story for Scientific American story at:
The Search for Life on Mars Is about to Get Weird
https://www.scientificamerican.com/article/the-search-for-life-on-mars-is-about-to-get-weird/
 Posted in


An ordinary construction brick, left, and an experimental brick made of a protein/lunar regolith mixture. |
Credit: Mia Allende
NASA and civil engineers at Stanford University have teamed up to explore use of a form of concrete to fabricate structures on the Moon and Mars.
David Loftus at NASA’s Ames Research Center reached out to Michael Lepech, an associate professor of civil and environmental engineering at Stanford School of Engineering. Lepech has been working on increasing environmental sustainability in construction, including ways to reduce the energy used in making concrete.
The researchers have used animal protein to make a promising form of concrete.
According to a Stanford press release, in search of a less energy-intensive alternative to make concrete, Loftus and Lepech turned to biology.
Slaughterhouses
Living organisms use proteins to make things as tough as shells, bones and teeth, so the researchers began working on a concrete bound together with a protein from bovine blood. The protein is a fairly cheap by-product of slaughterhouses, and it is known to become very gluey when mixed with soil.
To replicate the conditions on Mars and the Moon, Lepech combined the protein with simulated extraterrestrial soils that are similar to what’s on Mars and the Moon. And because Mars has much lower gravity than Earth – bad for cement mixing – the researchers applied a vacuum technology used to make composite materials in products such as boat hulls.
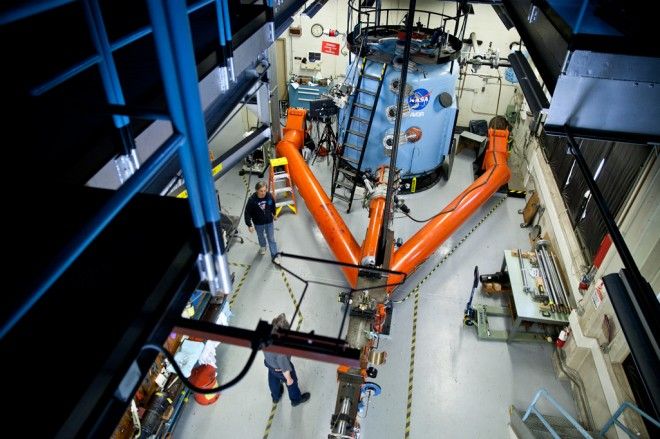
NASA Ames Vertical Gun Range.
Credit: NASA
Recycled organic waste
The first batch was as strong as the concrete used for sidewalks and patios – a good start. It also held up well to a simulated bombardment of micrometeorites, which the researchers replicated by taking the material to the Ames Vertical Gun Range and blasting it with high-speed gas particles.
For the purposes of making concrete off Earth, the idea is to create biological “factories” of organisms that are genetically engineered to produce the protein binder. It’s the same way that biotech companies use genetically engineered bacteria to make synthetic hormones. The feedstock for those organisms would come from the settlement’s recycled organic waste.
Lepech says that bio-concrete isn’t yet ready for buildings and roads on Earth – but that it could be.
Credit: USAF
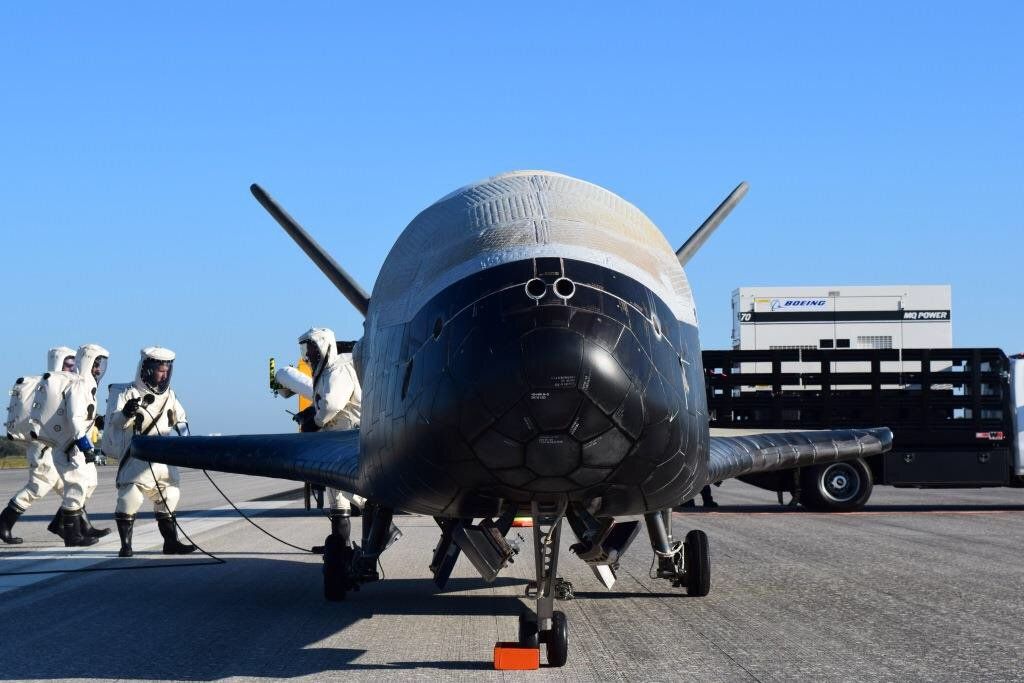
The record-setting, hush-hush mission by the U.S. Air Force’s X-37B space plane returned to Earth this morning, touching down for the first time at the Kennedy Space Center (KSC).
Launched from Florida atop an Atlas booster on May 20, 2015, the OTV-4 (Orbital Test Vehicle-4) has performed the program’s longest duration flight.
The Air Force is preparing to launch the fifth X-37B mission from Cape Canaveral Air Force Station later in 2017, according to the Air Force statement released this morning.
The OTV-4 conducted on-orbit experiments for 718 days during its mission, extending the total number of days spent on-orbit for the OTV program to 2,085 days.
The robotic mini-space plane is one of two reusable X-37B vehicles that constitute the space plane “fleet.” The just-ended OTV-4 space trek is the second flight of the second X-37B vehicle built for the Air Force by Boeing.
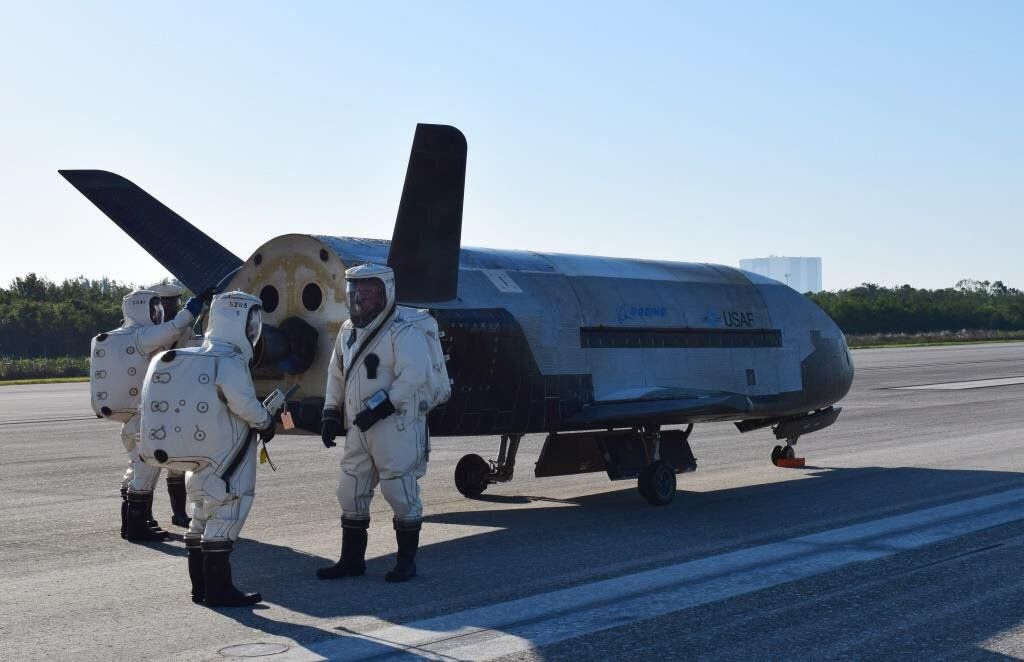
Credit: USAF
Safe and successful
“Today marks an incredibly exciting day for the 45th Space Wing as we continue to break barriers,” said Brig. Gen. Wayne Monteith, 45th Space Wing commander. “Our team has been preparing for this event for several years, and I am extremely proud to see our hard work and dedication culminate in today’s safe and successful landing of the X-37B,” Monteith said in an Air Force press statement.
Appearing like a miniature version of NASA’s now-retired space shuttle orbiter, the reusable military space plane is 29 feet (8.8 meters) long and 9.6 feet (2.9 meters) tall, and has a wingspan of nearly 15 feet (4.6 meters).
The space drone has a payload bay about the size of a pickup truck bed that can be outfitted with a robotic arm. It has a launch weight of 11,000 pounds (4,990 kilograms) and is powered on orbit gallium arsenide solar cells with lithium-ion batteries.

The X-37B Orbital Test Vehicle mission 4 (OTV-4), the Air Force’s unmanned, reusable space plane, landed at NASA’s Kennedy Space Center Shuttle Landing Facility May 7, 2017.
Credit: USAF
Tight-lipped affair
A third mission of the Boeing-built X-37B Orbital Test Vehicle was completed on Oct. 17, 2014, when it landed and was recovered at Vandenberg Air Force Base in California following a successful 674-day space mission.
OTV-4 has shattered that previous long-duration flight achievement.
What this “winged warrior” did high above Earth is an on-going, tight-lipped affair. But for this mission, some payloads onboard the OTV-4 craft were previously identified.
For example, Aerojet Rocketdyne has said that its XR-5A Hall Thruster had completed initial on-orbit validation testing onboard the X-37B space plane. Also onboard was a NASA advanced materials investigation.
Track record
The first OTV mission began April 22, 2010, and concluded on Dec. 3, 2010, after 224 days in orbit.
The second OTV mission began March 5, 2011, and concluded on June 16, 2012, after 468 days on orbit.
An OTV-3 mission chalked up nearly 675 days in orbit when it landed Oct. 17, 2014.
KSC landing
Previously, all the OTV craft to date guided their way on auto-pilot to a Vandenberg Air Force Base, California tarmac-touchdown.
That has changed with the OTV-4 mission touchdown at KSC. Work has long been underway to consolidate X-37B space plane operations, including use of NASA’s Kennedy Space Center in Florida as a landing site for the robotic space plane.
A former KSC space-shuttle facility known as Orbiter Processing Facility (OPF-1) was converted into a structure that enables the Air Force “to efficiently land, recover, refurbish and relaunch the X-37B Orbital Test Vehicle (OTV),” according to Boeing.
The X-37B vehicle development falls under the Boeing Space and Intelligence Systems in El Segundo, California, the firm’s center for all space and experimental systems and government and commercial satellites.
The Air Force Rapid Capabilities Office is leading the Department of Defense’s OTV initiative, by direction of the Under Secretary of Defense for Acquisition, Technology and Logistics and the Secretary of the Air Force.
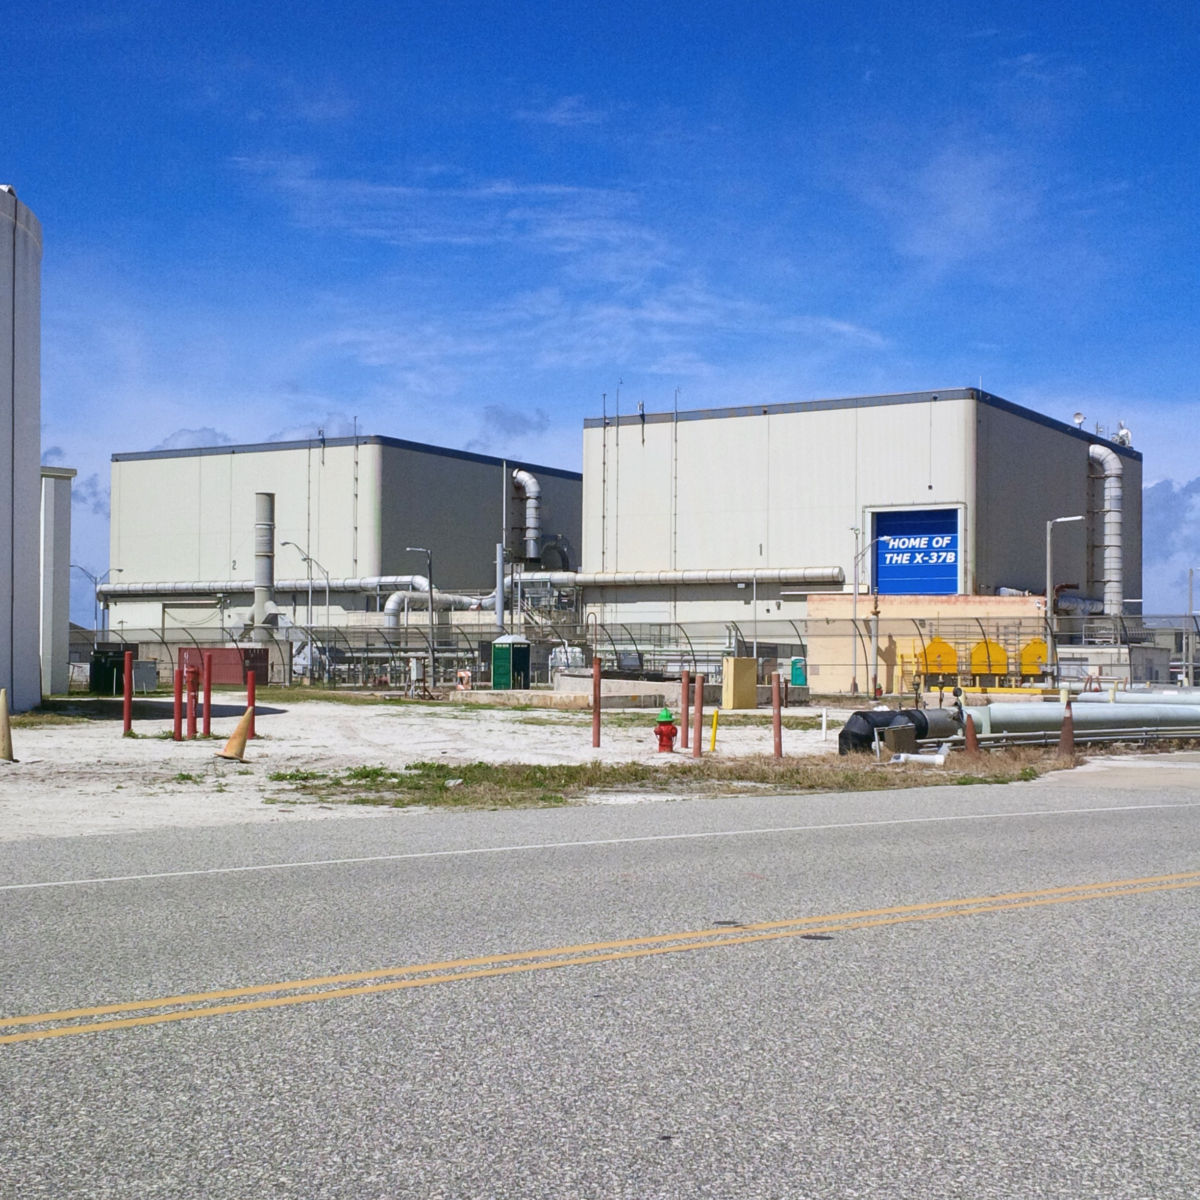
Former shuttle processing area at the Kennedy Space Center has been overhauled by Boeing to prep the military’s secretive X-37B space plane.
Credit: Malcolm Glenn
Pleased with performance
“The landing of OTV-4 marks another success for the X-37B program and the nation,” said Lt. Col. Ron Fehlen, X-37B program manager.
“This mission once again set an on-orbit endurance record and marks the vehicle’s first landing in the state of Florida. We are incredibly pleased with the performance of the space vehicle and are excited about the data gathered to support the scientific and space communities. We are extremely proud of the dedication and hard work by the entire team,” Fehlen said in the Air Force press statement.
“The hard work of the X-37B OTV team and the 45th Space Wing successfully demonstrated the flexibility and resolve necessary to continue the nation’s advancement in space,” said Randy Walden, Director of the Air Force Rapid Capabilities Office.

A previous X-37B being readied for launch atop Atlas booster. Next mission — OTV-5 — is set to fly by close of 2017.
Credit: Boeing
“The ability to land, refurbish, and launch from the same location further enhances the OTV’s ability to rapidly integrate and qualify new space technologies,” Walden said.
Check out this landing view from the Secretary of the Air Force, at:
https://www.dvidshub.net/video/523061/x37b-otv4-landing-runway
Also, go to:
https://www.dvidshub.net/video/523059/x37b-otv4-landing-profile
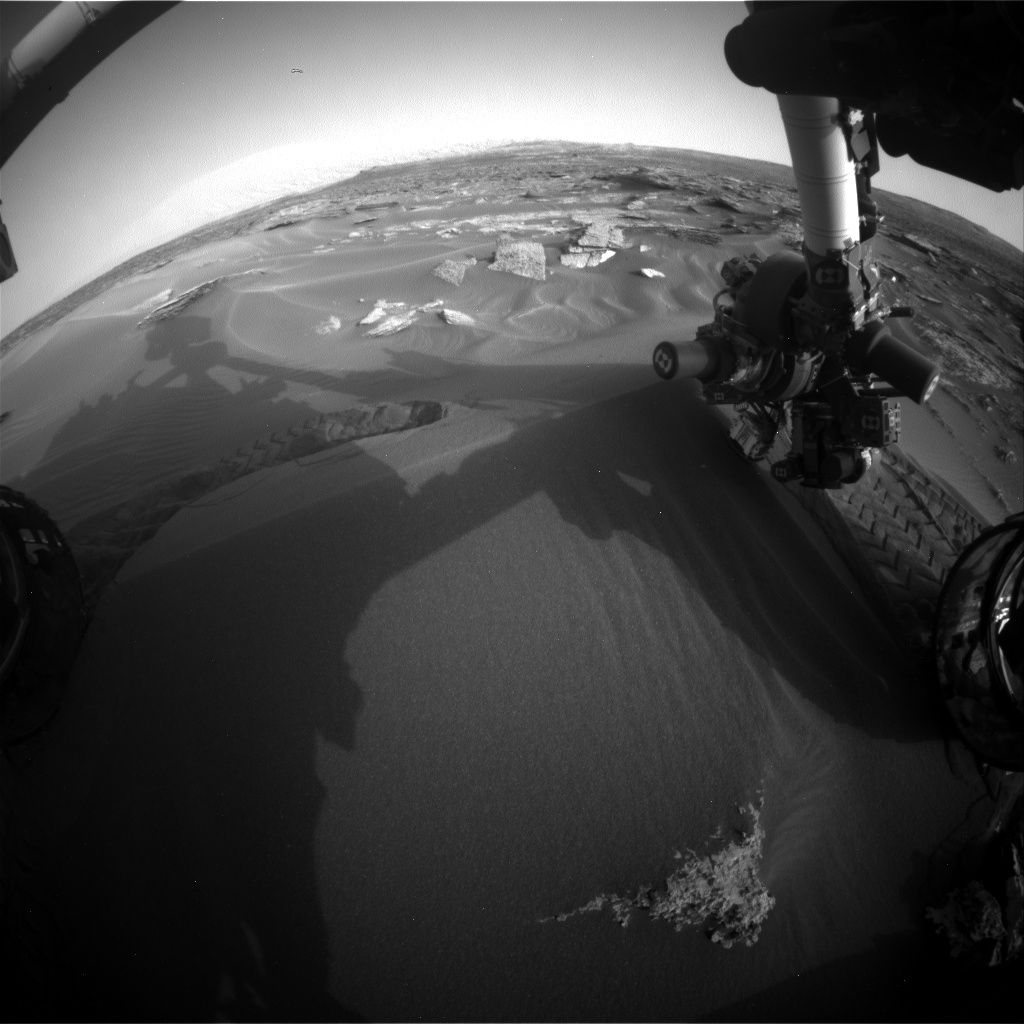
Curiosity Hazcam Right B image acquired on Sol 1688, May 6, 2017.
Credit: NASA/JPL-Caltech
NASA’s Curiosity Mars rover is now performing Sol 1689 science duties
Reports Michelle Minitti, a planetary geologist for Framework in Silver Spring, Maryland, the robot has parked itself in front of a megaripple.
Compare and contrast
In surveying the sandy feature, scientists are studying its physical and chemical characteristics, comparing and contrasting it to the sands investigated during the rover’s recent Bagnold dune campaign.
Over the weekend, the plan calls for high priority observations of the megaripple, Minitti notes.
Curiosity planning includes Mars Hand Lens Imager (MAHLI) and Alpha Particle X-Ray Spectrometer (APXS) observations of the target “Schoolhouse Ledge” along the ripple crest, and the target “Man of War Brook” along the flank of the ripple.
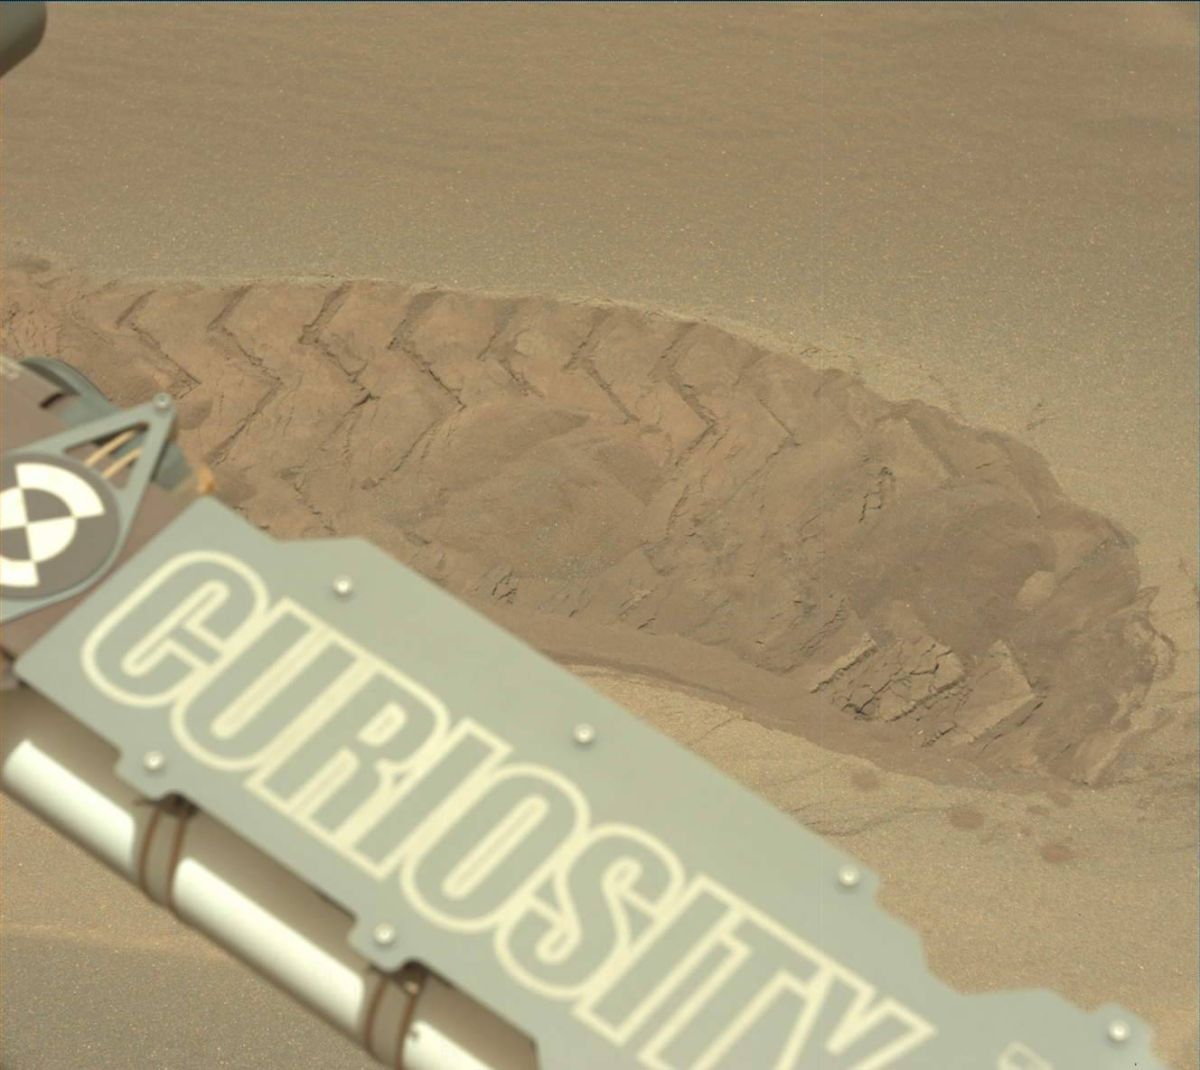
Curiosity Mastcam Left image taken on Sol 1686, May 4, 2017.
Credit: NASA/JPL-Caltech/MSSS
Wheel scuff
To keep the structure of the ripple crest pristine for MAHLI photography, the rover’s Chemistry & Camera (ChemCam) shot laser pulses across another part of the ripple crest – the target “Gilpatrick Ledge.”
“We also used ChemCam to interrogate the target “The Gorge,” located inside the wheel scuff the rover planners purposely cut into the ripple to expose its interior structure,” Minitti adds.
Iron-bearing minerals
Also in the plans was use of the robot’s Mastcam, using filters at specific wavelengths of light to help constrain what iron-bearing minerals are present within the sands.
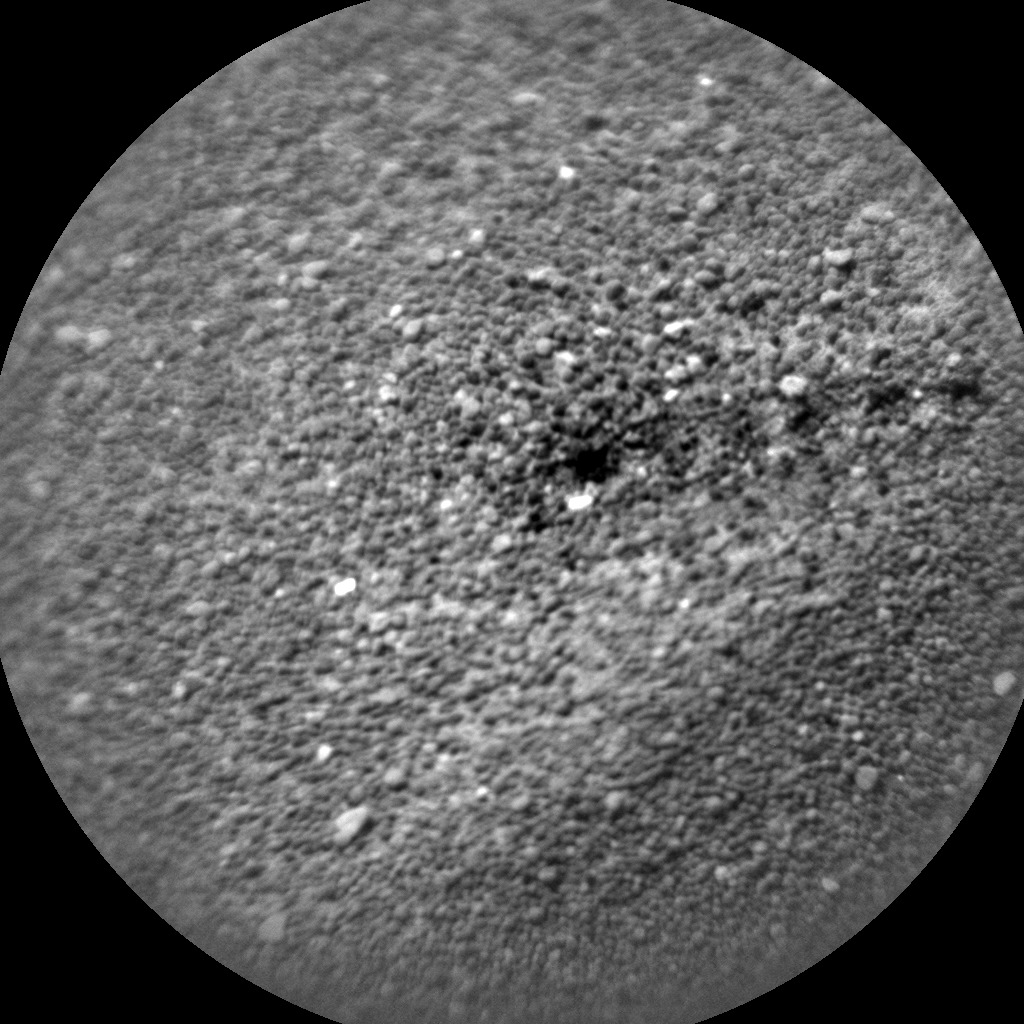
Laser pulses dot sand dune. Curiosity ChemCam Remote Micro-Imager photo taken on Sol 1687, May 5, 2017.
Image Credit: NASA/JPL-Caltech/LANL
The target for this observation was “Cobbosseecontee Lake,” which one Maine-dwelling member of the science team insisted was not challenging to say. It is actually pretty phonetic, Minitti suggests.
Well-layered bedrock
“Even with our focus on the megaripple,” Minitti adds, “there was still time to image the rocks around us with Mastcam, including an expanse of well-layered bedrock south of us called “Amphitheater Valley.”
Lastly, Curiosity began taking a series of Mars Descent Imager (MARDI) images – “one image acquired each evening we are parked at the megaripple – to look for wind-induced changes,” Minitti notes. “These change detection images help the team understand if (or how) wind activity and direction are changing as we leave the Bagnold dunes.”
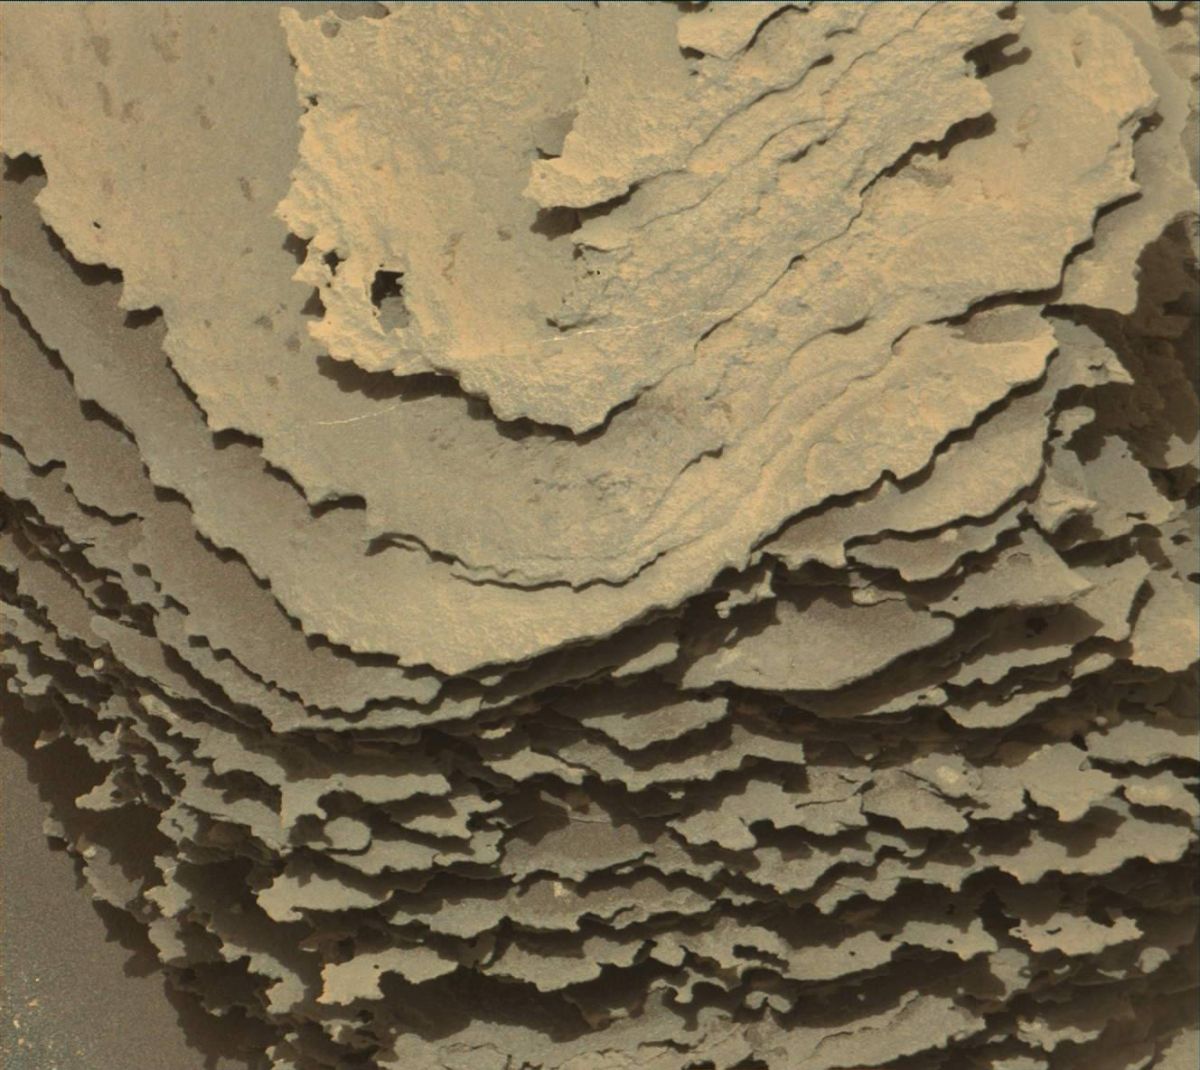
Curiosity Mastcam Right image taken on Sol 1686, May 4, 2017.
Credit: NASA/JPL-Caltech/MSSS
Also on the schedule is a dust devil survey to look for telltale signs of wind activity, as well as acquiring a long Dynamic Albedo of Neutrons (DAN) passive observation, and taking regular Radiation Assessment Detector (RAD) and Rover Environmental Monitoring Station (REMS) measurements.
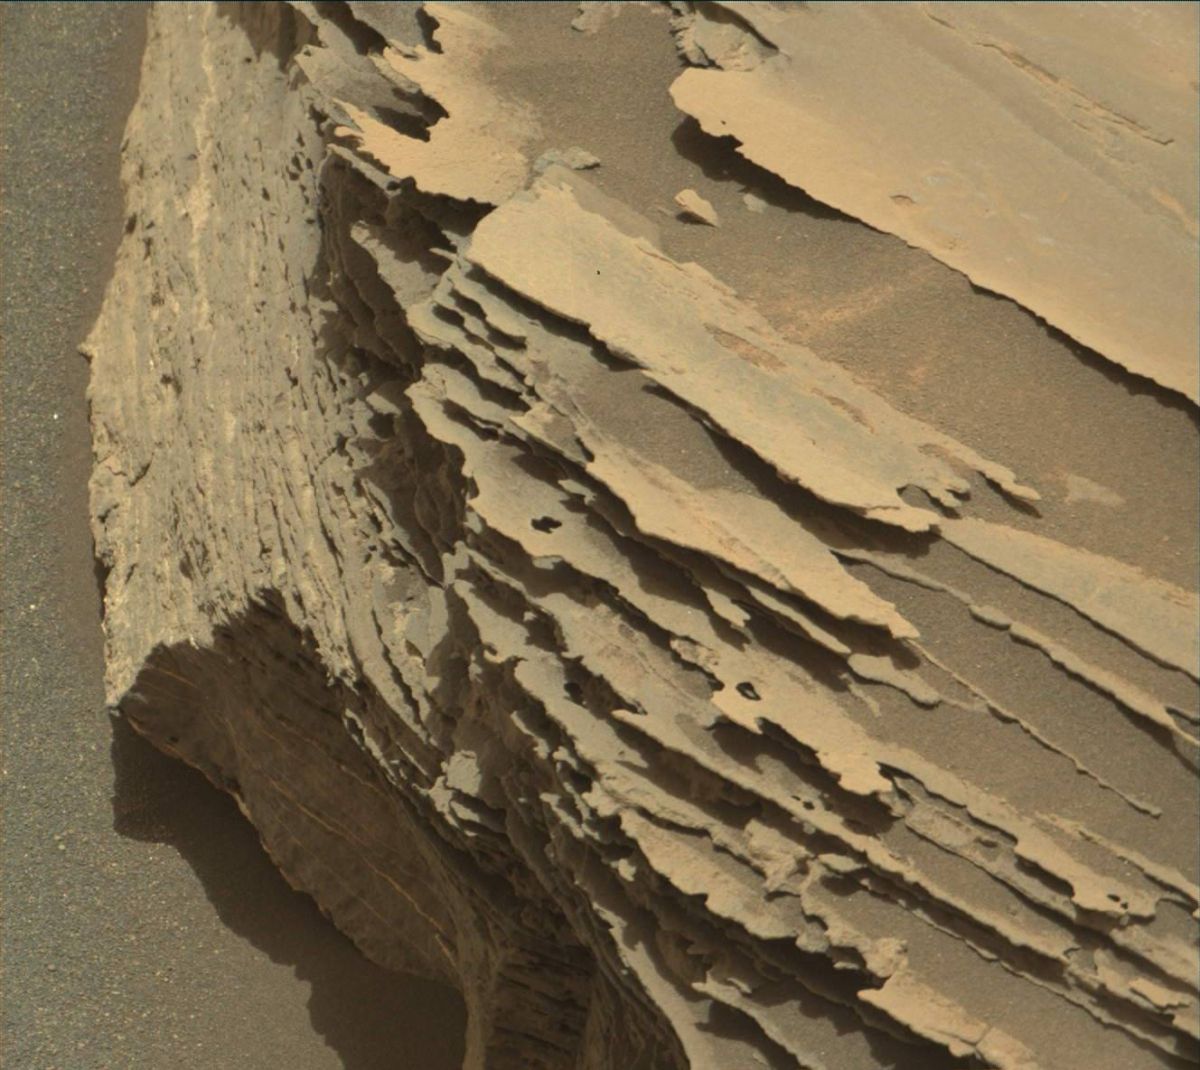
Curiosity Mastcam Right image taken on Sol 1686, May 4, 2017.
Credit: NASA/JPL-Caltech/MSSS
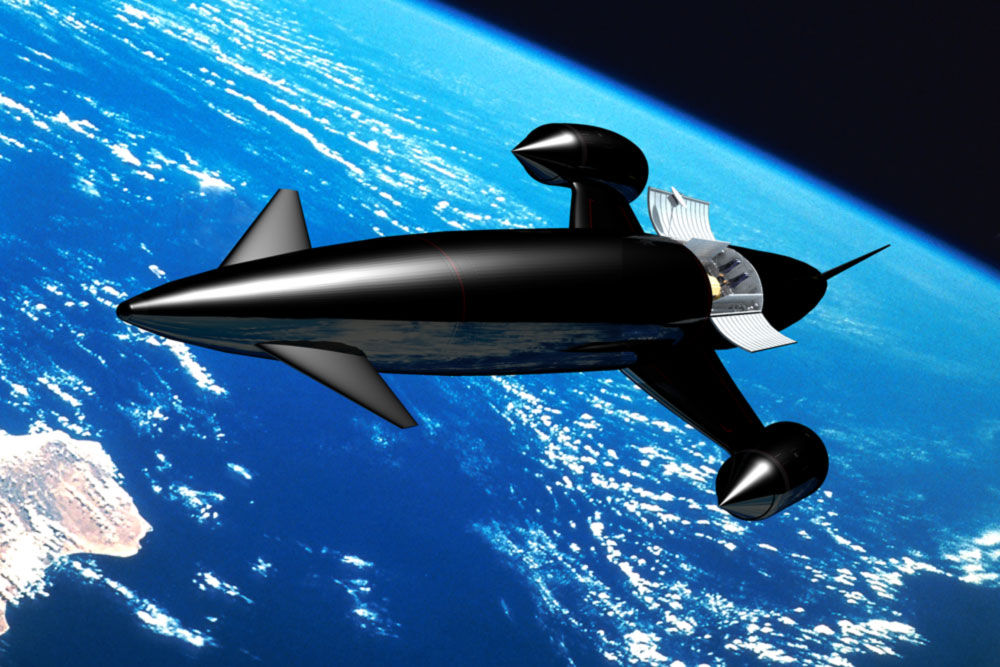
Artwork depicts Skylon space transportation.
Credit: Reaction Engines
The on-going revolution in access to Earth orbit is getting a boost by a new engine test facility.
The Synergistic Air-Breathing Rocket Engine (SABRE) project has been underway for many years, work undertaken by the UK firm, Reaction Engines Ltd.
Work began this week on building the UK’s latest rocket engine test facility, designed for firing the engine core of the SABRE propulsion system within three years.
Ground was broken on the new test facility at Westcott Venture Park in the UK, an historic site for rocket research over the past seven decades.
Test site
The new site will consist of a multipurpose propulsion test stand designed to accommodate various test engine configurations, an assembly building, workshops, offices and control room.
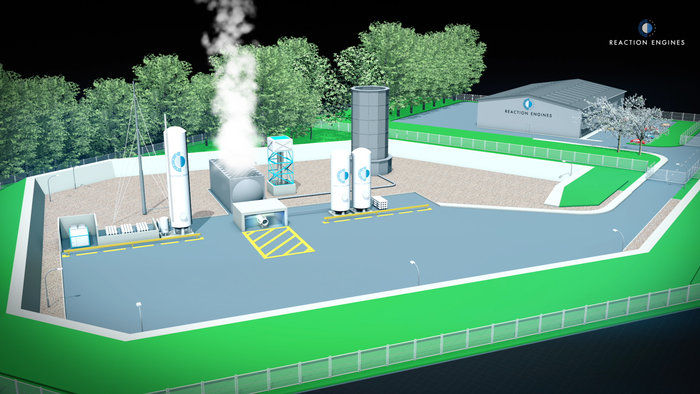
Ground was broken on the new test facility at Westcott Venture Park in the UK.
Credit: Reaction Engines
The location of workshops and other support facilities alongside the test stand will enable configuration changes to the engine to take place at the site, reducing the down time between testing phases and accelerating the engine’s development.
The big scoop
The promise of the SABRE propulsion system concept is to scoop up atmospheric air during the early part of its flight to orbit.
Doing so slashes the need for the vehicle to carry bulky onboard oxygen for this part of the ascent, before switching to rocket mode drawing on internal propellants for its final climb to space.
Single-stage-to-orbit
SABRE is a hybrid jet and rocket engine designed for a single-stage-to-orbit space plane. Incorporating innovative precooler technology able to chill superheated air in a fraction of a second, SABRE would use oxygen from the atmosphere until it reaches above Mach 5, after which it would shift to a closed-cycle rocket mode.
The concept paves the way for lighter and reusable spaceplanes able to fly from conventional runways.
Reaction Engines’ plan for SABRE is to power the over 275-foot long (84 meters) pilotless Skylon.
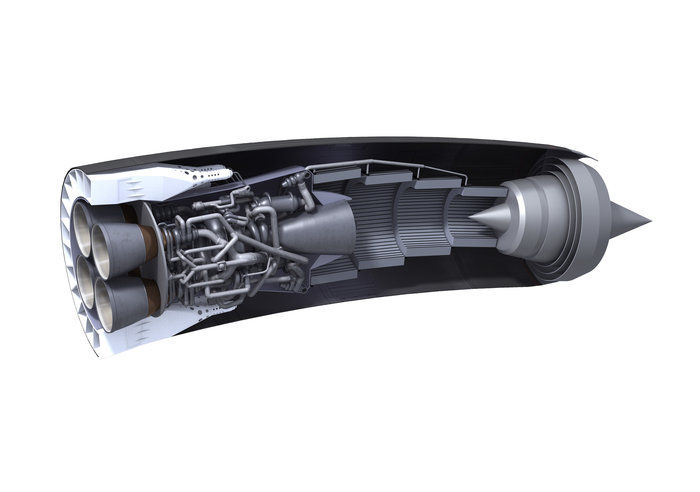
Synergistic Air-Breathing Rocket Engine (SABRE).
Credit: Reaction Engines
Cash flow
According to the European Space Agency, ESA has invested in SABRE, following a 2010 independent review of the engine’s viability, “opening the way” to UK government investment. Reaction Engines Ltd has subsequently received private investment from BAE Systems, focused on accelerating development.
Such engines have the potential to revolutionize space launches, powering vehicles that can take off and land like aircraft. Capable of airbreathing flight up to Mach 5 (five times the speed of sound) they could also lead to hypersonic air travel, according to an ESA press statement.
For more information on Reaction Engines Ltd. go to:
https://www.reactionengines.co.uk/
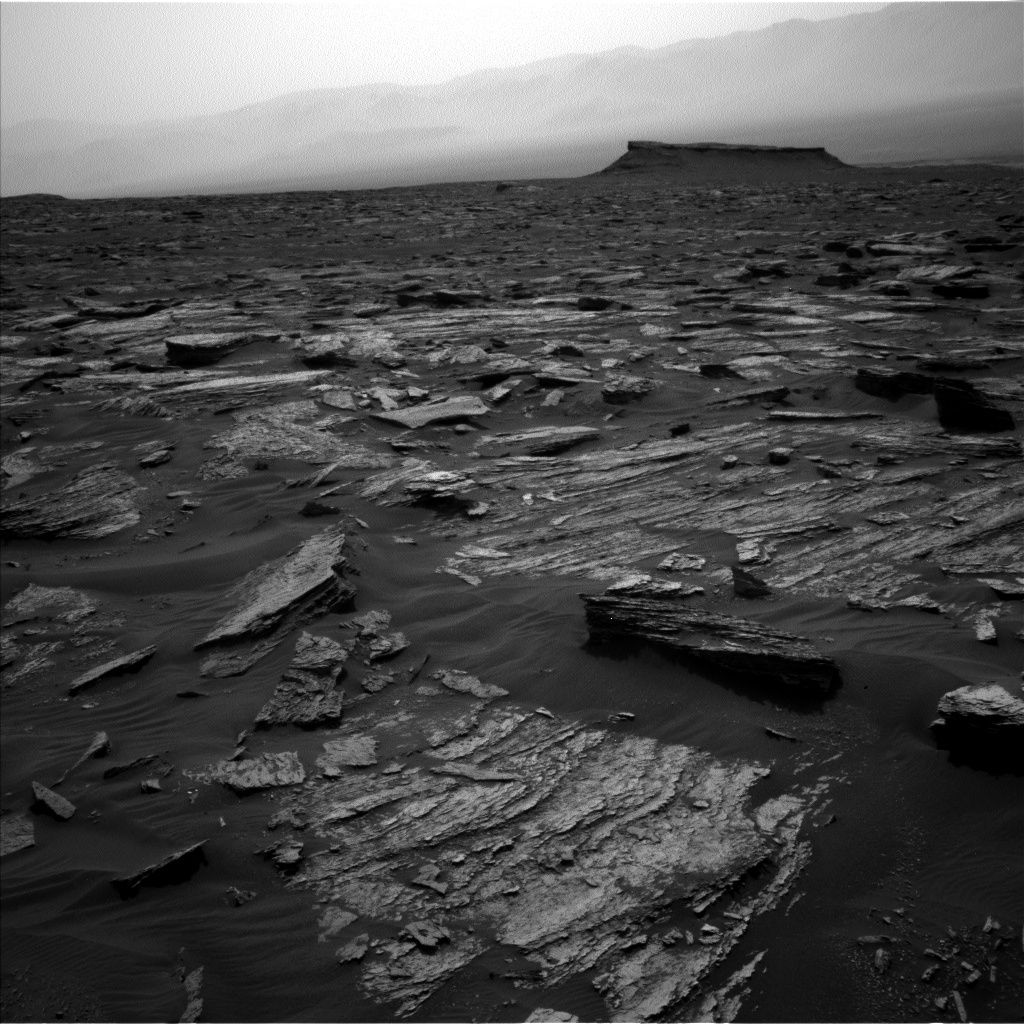
Curiosity Navcam Left B image taken on Sol 1685, May 3, 2017.
Credit: NASA/JPL-Caltech
NASA’s Curiosity rover is now performing Sol 1686 science duties, “continuing the steady march up Mt. Sharp,” reports Michael Battalio, an atmospheric scientist; from Texas A&M University.
Curiosity recently drove 60 feet (18.3 meters) to bring the robot closer to a series of features being called “megaripples” – darker and larger ripples than were seen on the Bagnold Dunes, Battalio adds.
Gauging grain size, distribution
Touch-and-go was again the planning option, with Curiosity carrying out contact science on two targets: “Newport Ledge” and “Sugarloaf Mountain.” These two targets are the closest two rocks protruding above the sand a recent Navcam image.
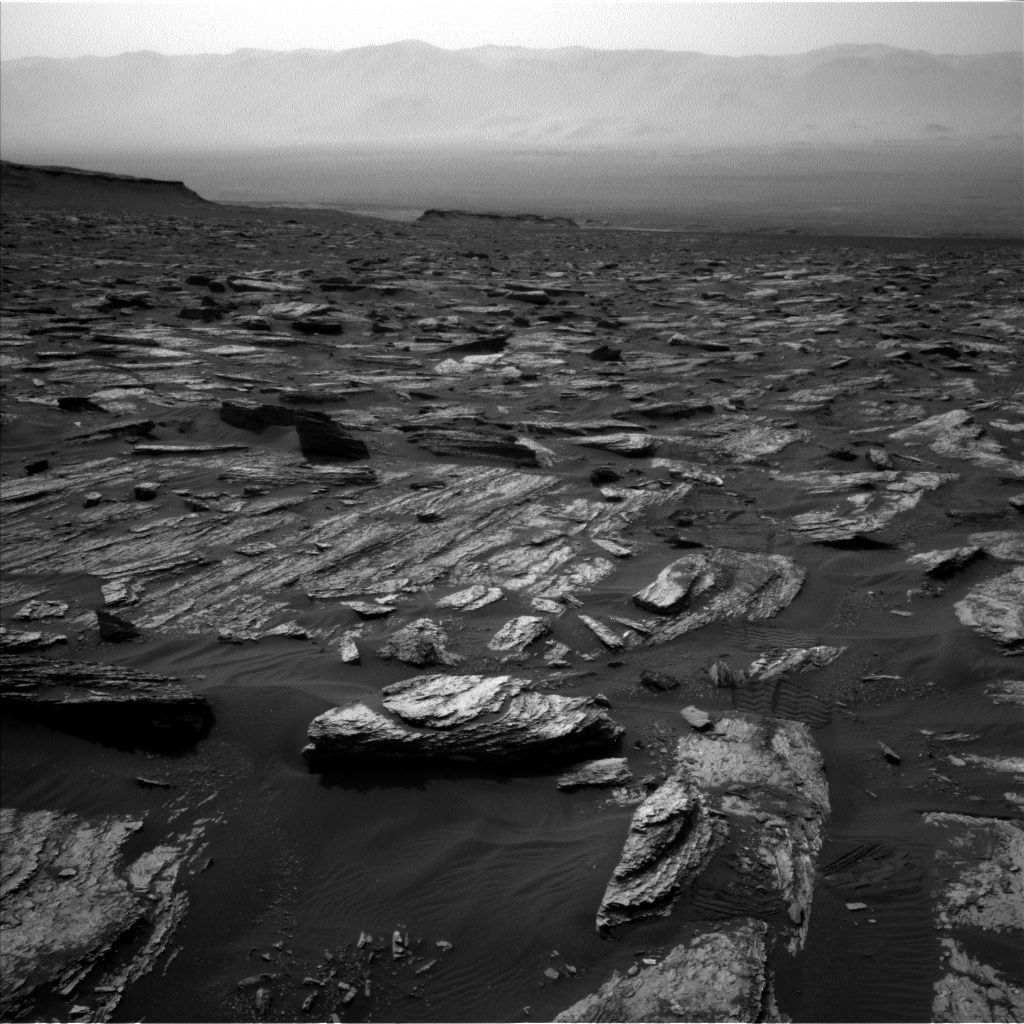
Curiosity Navcam Left B image taken on Sol 1685, May 3, 2017.
Credit: NASA/JPL-Caltech
Curiosity’s Mars Hand Lens Imager (MAHLI) is scheduled to target Newport Ledge to gauge grain size and distribution.
A series of observations by the robot’s Alpha Particle X-Ray Spectrometer (APXS) and Chemistry & Camera (ChemCam) on Newport Ledge, Battalio adds, will continue to investigate the variations in the Murray bedrock over the course of the ascent up Mt. Sharp.
Stratification and layering
The rover’s Mastcam is slated to target Newport Ledge and Sugarloaf Mountain to look at stratification and layering.
After a drive that should take Curiosity to the edge of the megaripples, ChemCam will perform an Autonomous Exploration for Gathering Increased Science (AEGIS) activity, and Navcam will document the robot’s new surroundings.
Also planned is a pair of afternoon dust observations with Mastcam, looking in the direction of the sun and towards the crater rim (a line-of-sight extinction).
Curiosity Front Hazcam Left B image taken on Sol 1685, May 5, 2017.
Credit: NASA/JPL-Caltech
Environmental measurements
As usual, the Rover Environmental Monitoring Station (REMS) will capture the top of the hour five-minute observations and hour-long blocks of environmental measurements, Battalio reports. “In addition, a two-hour block of high-resolution data for the humidity sensor will be taken in the early morning.”
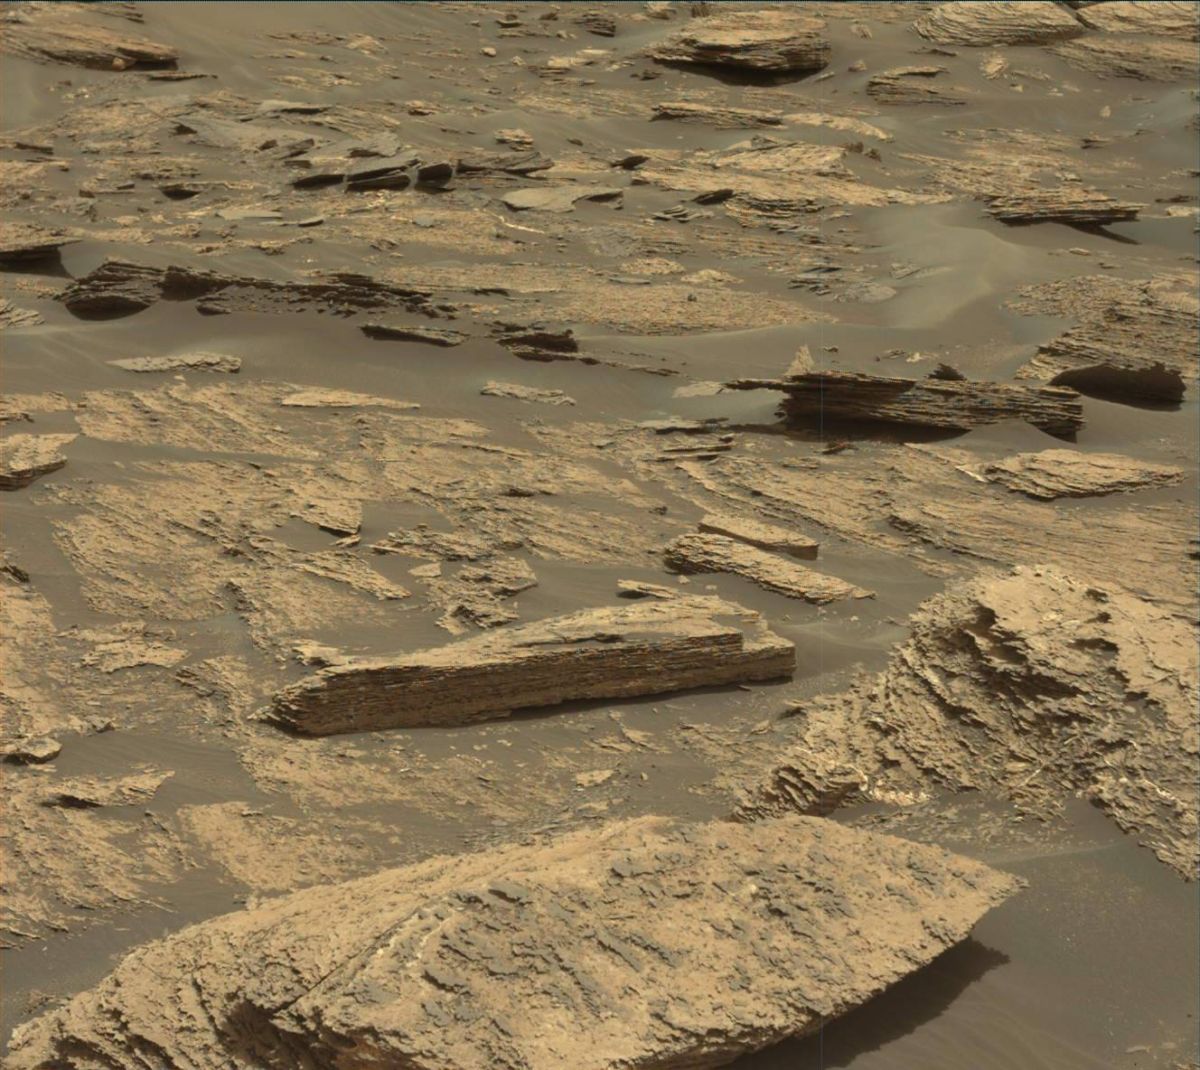
Curiosity Mastcam Left image taken on Sol 1684, May 2, 2017.
Credit: NASA/JPL-Caltech/MSSS
The high-resolution capture of humidity data, Battalio adds, “is only sparingly used because it requires the ground temperature and wind sensors to be turned off as the heat they generate interferes with the humidity measurements.”
Also, a Dynamic Albedo of Neutrons (DAN) passive and post-drive active measurement will be acquired as well.
New traverse map
Since landing in August 2012, Curiosity has driven 10.12 miles (16.29 kilometers) as of Sol 1685.
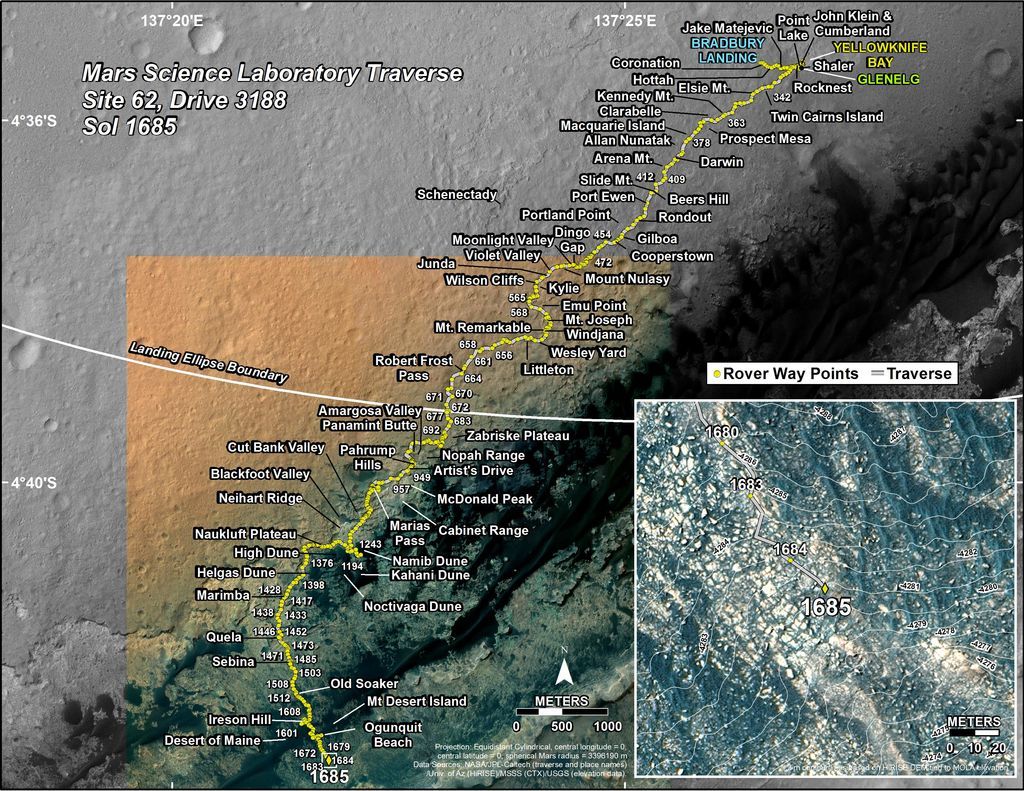
This map is periodically updated by the mission team as Curiosity drives on its way to the base of Mount Sharp.
Credit: NASA/JPL-Caltech
The base image from the map is from the High Resolution Imaging Science Experiment Camera (HiRISE) onboard NASA’s Mars Reconnaissance Orbiter.
Credit: NASA/JPL-CalTech/University of Arizona
A new map has been issued showing Curiosity’s traverse over Mars through Sol 1685.
This map shows the route driven by NASA’s Mars rover Curiosity through the 1685 Martian day, or sol, of the rover’s mission on Mars (May 03, 2017).
Numbering of the dots along the line indicate the sol number of each drive. North is up. The scale bar is 1 kilometer (~0.62 mile).
From Sol 1684 to Sol 1685, Curiosity had driven a straight line distance of about 60.01 feet (18.29 meters), bringing the rover’s total odometry for the mission to 10.12 miles (16.29 kilometers).

Credit: Lockheed Martin
Got an artistic pallet for the Red Planet? While placing humans on Mars is years off, what does the future hold for people surviving and thriving on that far flung world?
Here’s your chance to match your artistic bent with humankind’s future trajectory to Mars.
SMArt contest
The Mars Society is sponsoring a Student Mars Art (SMArt) Contest, inviting youth from around the world to depict the human future on Mars.
Young artists from grades 4 through 12 are invited to submit up to three works of art each, illustrating any part of our future on the Red Planet.
Mars art will consist of still images, which may be composed by traditional methods, such as pencil, charcoal, watercolors or paint, or by computerized means.
Deadline approaching
Artwork, for example, could spotlight the first landing, human field exploration, operations at an early Mars base, the building of the first Martian cities, terraforming the Red Planet and other related human settlement concepts.
The deadline for submissions: May 31, 2017, 5:00 pm, Mountain Standard Time (MST).

Credit: NASA
Categories
The SMArt Contest will be divided into three categories: Upper Elementary (grades 4-6), Junior High (grades 7-9), and High School (Grades 10-12).
Cash prizes of $1,000, $500 and $250, as well as trophies, will be given out to the first, second and third place winners of each section.
There will also be certificates of honorable mention for those artists who don’t finish in the top three, but whose work is nevertheless judged to be particularly meritorious.
Winning works
The winning works of art will be posted on the Mars Society web site and may also be published as part of a special book about Mars art.
Credit: Mars Society
Winners will also be invited to come to the 20th Annual International Mars Society Convention at the University of California, Irvine September 7-10, 2017 to display and discuss their art.
NOTE: Works of art must be submitted via a special online form:
http://nextgen.marssociety.org/mars-art in either PDF or JPEG format with a 10 MB limit per image.
By submitting art to the contest, participating students grant the Mars Society non-exclusive rights to publish the images on its web site or in Kindle paper book form.
All questions about the Mars Society’s SMArt Contest can be submitted to: Marsart@marssociety.org

Test bedding 3D manufacturing onboard the International Space Station.
Credit: NASA
A way to launch tiny, postage stamp-sized satellites called “Femtosatellites” is the winning design of an International Space Station Design Challenge.
The Femtosatellite launcher idea was chosen from 242 entries, and then digitally transmitted to the ISS where it was 3D-printed on April 3 by Made In Space’s Additive Manufacturing Facility (AMF) – the first commercially available off-world manufacturing service.
Mouser Electronics Inc. and inventor Grant Imahara today released official footage (below) of the winning design.
Last-minute modifications
“Mouser brought together engineers, students and makers from around the world in this exciting design challenge. All the designs were excellent, but in the end there was one design that stood above the rest,” said Glenn Smith, President and CEO of Texas-based Mouser Electronics, underscoring engineer Andy Filo’s winning design.
Made In Space and Filo made last-minute modifications after the ISS received the original design, rounding the handle to increase usability and comfort and further editing the design to increase printing speed.
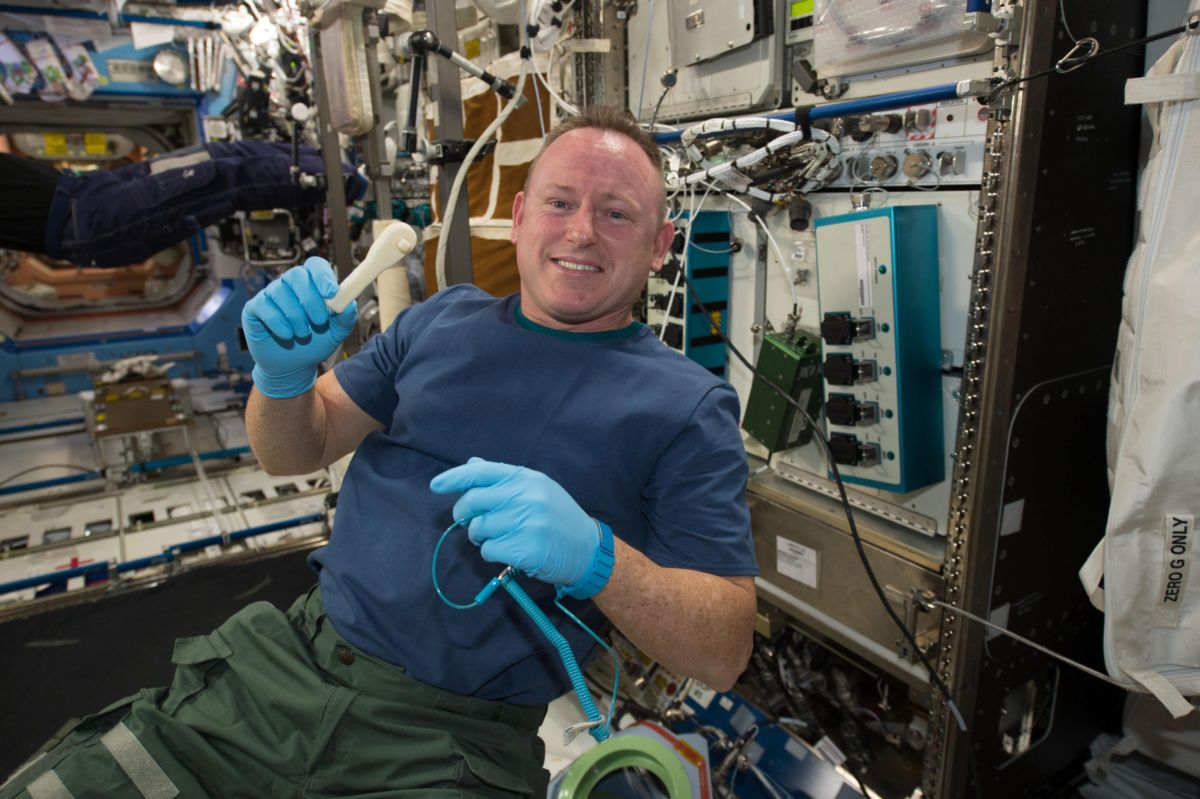
Ratcheting up use of 3D printing onboard the International Space Station. NASA Astronaut Barry (Butch) Wilmore holds a 3-D printed ratchet wrench from the new 3-D printer aboard the International Space Station. The printer completed the first phase of a NASA technology demonstration by printing a tool with a design file that was transmitted from the ground to the printer.
Credit: NASA
Missions and applications
Femtosatellites weigh less than 100 grams and researchers can use them for a variety of missions and applications, including monitoring disasters, cosmic rays and coronal events, according to a Mouser statement.
Mouser suppliers, Amphenol and Intel®, were co-sponsors of the space station design challenge, and also partnered with the Institute of Electrical and Electronics Engineers, Made In Space and MacroFab.
To video view this winning design, go to:
https://www.youtube.com/watch?v=-3-c0eJS4-Y&feature=youtu.be
Also, take a look at this video:
https://www.youtube.com/watch?v=c_3TangcGnM&feature=youtu.be

Mars true-color globe showing Terra Meridiani.
Credits: NASA/Greg Shirah
An international flotilla of new spacecraft — orbiters and landers — is slated to arrive at Mars in 2021, creating an unprecedented telecommunications challenge for NASA’s Deep Space Network (DSN).
These spacecraft all need to communicate with Earth en route to Mars, requiring large amounts of telemetry and tracking after launch and then on approach to the red planet. The sheer number of Mars-bound craft, launched by multiple nations, may stress NASA’s ground tracking network and capabilities of international partners.
For more information, please go to my new SpaceNews story at:

Credit: NASA, ESA, and the Hubble Heritage Team (STScI/AURA)
Acknowledgement: William Blair (Johns Hopkins University)
Here on Earth, researchers are on the lookout for microbial or, at best, unintelligent life.
But finding leftover technological artifacts by prior technological, perhaps spacefaring, species could be easier to locate.
Be prepared to detect unambiguous “technosignatures” is the advice of Jason Wright at the Pennsylvania State University’s Department of Astronomy & Astrophysics and Center for Exoplanets and Habitable Worlds.
Archeology of space
“While all geological records of prior indigenous technological species might be long destroyed, if the species were spacefaring there may be technological artifacts to be found throughout the Solar system,” Wright explains in a recent research paper, now in the production phase after being accepted for publication in the International Journal of Astrobiology.

Outward bound Voyager records with photos, messages, sounds.
Credit: NASA
Indeed, technosignatures could be in the form of artifacts beneath the surface of Mars, the rocky moons and asteroids, or in orbit in the outer Solar System where they could be discoverable.
“Such discoveries might occur using the tools of the burgeoning field of the archeology of space, which includes searching for, finding, and interpreting human artifacts in space,” Wright adds. “Such work includes the rediscovery and identification of lost probes and other space-borne human artifacts either for forensic purposes, or even accidentally.”
Buried structures
Wright suggests that more likely is revealing traces of buried structures or other artifacts via imagery and subsurface radar used to study the geology of planetary surfaces.
“Photometry and spectra of asteroids, comets, and Kuiper Belt Objects might reveal albedo, shape, rotational, compositional, or other anomalies because the targets host, or are, artifacts,” Wright explains.
Mars true-color globe showing Terra Meridiani.
Credits: NASA/Greg Shirah
The origins and possible locations for technosignatures of a prior indigenous technological species, Wright says, might be found on ancient Earth or another body, such as a pre-greenhouse Venus or a wet Mars of long ago.
Unambiguous technosignatures
“Remaining indigenous technosignatures might be expected to be extremely old, limiting the places they might still be found…beneath the surfaces of Mars and the Moon, or in the outer Solar System,” Wright suggests.
“The question is not how long the past we might be able to detect the fossil remains of the species — we don’t know how to measure intelligence reliably from fossils of bones — but to detect unambiguous technosignatures,” he writes.
Wright’s research was partially supported by Breakthrough Listen, part of the Breakthrough Initiatives sponsored by the Breakthrough Prize Foundation.
For the full research paper, go to Prior Indigenous Technological Species at:

