Archive for the ‘Space News’ Category
 Author:
 November 22nd, 2019

Credit: CNSA/CLEP
China’s Chang’e-4 farside lander and rover have “self-awakened” on Thursday.
The exploration twosome have entered their 12th lunar day within the Von Karman Crater in the South Pole-Aitken Basin, according to the Lunar Exploration and Space Program Center of the China National Space Administration.

Chang’e-4 farside mission – lander and Yutu-2 rover
Credit: CNSA/CLEP
Stable state
The Yutu-2 rover woke up at 0:51 a.m. Beijing Time (BJT) and the lander at 5:03 p.m. BJT. Both devices and the specially positioned relay satellite are working normally and are in a stable state. The data reception and processing of ground stations are normal.

Queqiao relay spacecraft is in a halo orbit around the second Lagrangian (L2) point of the Earth-Moon system, utilized to set up a communication link between the Earth and the Moon’s farside.
Credit: CNSA
The probe has spent 322 days working on the farside of the Moon, and the rover has traveled roughly 1,045 feet (318.62) meters across the lunar landscape.
Scientific payloads
During this working period, the lunar surface neutron and radiation dose detector, low-frequency radio frequency spectrometer and other scientific payloads on the lander will continue scientific exploration of the lunar surface environment.
The Yutu-2 rover will keep following a planned route.
The panoramic camera, lunar radar, infrared imaging spectrometer, neutral atom detector and other scientific payloads on the rover will carry out scientific exploration at different detection points.
Chang’e-4 was dispatched to the Moon on December 8, 2018, making the first-ever soft landing on the farside of the Moon.

Chang’e-5 mission is intended to return lunar specimens back to Earth.
Credit: CCTV/Screengrab/Inside Outer Space
Return sample mission
Meanwhile, work is ongoing on readying the Chang’e-5 mission for launch in 2020, designed to rocket back to Earth 4.4 pounds (2 kilograms) of lunar samples.
That mission, however, is predicated on a successful return-to-flight of the powerful Long March-5 carrier rocket.

Long March-5 booster’s first liftoff occurred in early November 2016. Mishap on launcher’s second flight in July 2017. Progress for a return-to-flight Long March-5 mission appears to be underway for possible flight late this year.
Credit: CASC
The second Long March-5 rocket roared from China’s Wenchang Space Launch Center in the southern province of Hainan on July 2, 2017. The flight suffered a malfunction less than six minutes after liftoff, causing an over two year mishap investigation by Chinese rocketeers.
The third Long March-5 rocket is now at the Wenchang Space Launch Center for a new flight, expected before year’s end.
 Posted in


Curiosity Mars Hand Lens Imager (MAHLI) photo produced on Sol 2592, November 21, 2019.
Credit: NASA/JPL-Caltech/MSSS
NASA’s Curiosity Mars rover is wrapping up Sol 2592 duties.
“Curiosity is continuing her exploration of Central Butte, focusing on characterizing the lithology of ledge-forming rocks in this area,” reports Lauren Edgar, a planetary geologist at the USGS Astrogeology Science Center in Flagstaff, Arizona.
A recently drafted plan has the robot carrying out several Chemistry and Camera (ChemCam) observations of “Ard Neakie” to assess a gray fractured zone, “Glen Doll” to characterize more typical bedrock adjacent to the fractured zone, and “Isle Ristol” to assess vertical changes in chemistry.

Curiosity Mars Hand Lens Imager (MAHLI) photo produced on Sol 2592, November 21, 2019.
Credit: NASA/JPL-Caltech/MSSS
Characterizing the bedrock
Edgar adds that the plan involves a lot of contact science as well, including Alpha Particle X-Ray Spectrometer (APXS) and a Mars Hand Lens Imager (MAHLI) full suite on “Glen Doll” and “Ard Neakie,” and a Dust Removal Tool (DRT), MAHLI full suite and overnight APXS on “Muckle Flugga” to characterize the bedrock at the rover’s location.
The Geology theme group also planned a Mastcam mosaic of “Muckle Flugga” and documentation of the ChemCam targets, Edgar notes.

Credit: NASA/JPL-CALTECH
The plan also includes typical Rover Environmental Monitoring Station (REMS) and Dynamic Albedo of Neutrons (DAN) observations and a Navcam atmospheric movie.
Edgar concludes: “I’m looking forward to seeing the results from all of the great contact science!”

Curiosity Front Hazard Avoidance Camera (Front Hazcam Left B) image taken on Sol 2590, November 19, 2019.
Credit: NASA/JPL-Caltech
NASA’s Curiosity Mars rover is now carrying out Sol 2591 tasks.
Reports Fred Calef, a planetary geologist at NASA’s Jet Propulsion Laboratory, Curiosity’s Central Butte campaign continues and the rover is traversing along an ever narrowing ledge.

Curiosity Front Hazard Avoidance Camera (Front Hazcam Left B) photo acquired on Sol 2590, November 19, 2019.
Credit: NASA/JPL-Caltech
“To continue forward, we need to take a few steps back and make a U-turn around to a less steep section to proceed,” Calef adds. “This ledge-forming material itself is an interesting pitted mudstone outcrop that we’d like to investigate.”

A view of possible pebble-forming rocks in front of the rover. A rock designated as “Quarff” is in the middle-left of the image.
Curiosity Left Navigation Camera Left B Sol 2590 November 19, 2019.
Credit: NASA/JPL-Caltech
Pebble forming block
The robot recently performed a touch-and-go maneuver taking Alpha Particle X-Ray Spectrometer (APXS), Chemistry and Camera (ChemCam), Mars Hand Lens Imager (MAHLI), and Mastcam measurements on a block called “Nedd.”
Nedd may be pebble forming and contributing to the surface texture viewed from orbit and on the ground, Calef points out.
Dipping strata
“In addition, we’ll get some Mastcam imaging on ‘Quarff,’ where we think there’s some dipping strata telling us how these rocks were laid down in the past. Also, we’ll acquire Mastcam of ‘Banffshire,’ our next drive location,” Calef reports.

Curiosity Left Navigation Camera Left B photo acquired on Sol 2590, November 19, 2019.
Credit: NASA/JPL-Caltech
“We wrap up the drive with some observations looking for dust devils and clouds for understanding wind direction,” Calef says. Last, but not least, a Mars Descent Imager (MARDI) image will be taken to document the smaller rocks (“clasts”) that make up the surface, he concludes.

Curiosity Left Navigation Camera Left B photo acquired on Sol 2590, November 19, 2019.
Credit: NASA/JPL-Caltech

Curiosity Left Navigation Camera Left B photo acquired on Sol 2590, November 19, 2019.
Credit: NASA/JPL-Caltech

Curiosity Left Navigation Camera Left B photo acquired on Sol 2590, November 19, 2019.
Credit: NASA/JPL-Caltech

Curiosity Mast Camera (Mastcam) Left image taken on Sol 2589, November 18, 2019.
Credit: NASA/JPL-Caltech/MSSS

Curiosity Mast Camera (Mastcam Left) photo taken on Sol 2590, November 19, 2019.
Credit: NASA/JPL-Caltech/MSSS

Curiosity Mast Camera (Mastcam) Left image taken on Sol 2589, November 18, 2019.
Credit: NASA/JPL-Caltech/MSSS

Micrograph of NIST’s high-resolution camera made of 1,024 sensors that count single photons, or particles of light. The camera was designed for future space-based telescopes searching for chemical signs of life on other planets. The 32-by-32 sensor array is surrounded by pink and gold wires connecting to electronics that compile the data.
Credit: V. Verma/NIST
Researchers at the National Institute of Standards and Technology (NIST) have made one of the highest-performance cameras ever composed of sensors that count single photons, or particles of light.
With more than 1,000 sensors — or pixels — NIST’s camera may be useful in future space-based telescopes searching for chemical signs of life on other planets, and in new instruments designed to search for the elusive “dark matter” believed to constitute most of the “stuff” in the universe.
The new NIST camera could efficiently capture light from atmospheres of extrasolar planets that possibly harbor life.
Superconducting nanowires
The NIST camera consists of sensors made from superconducting nanowires, which can detect single photons. According to a NIST statement, they are among the best photon counters in terms of speed, efficiency, and range of color sensitivity. A NIST team used these detectors to demonstrate Einstein’s “spooky action at a distance,” for example.
NIST’s camera is small in physical size: It is a square measuring 1.6 millimeters on a side, but packed with 1,024 sensors (32 columns by 32 rows) to make high-resolution images.

Credit: NASA
NASA requirements
The main challenge was to find a way to collate and obtain results from so many detectors without overheating. The researchers extended a “readout” architecture they previously demonstrated with a smaller camera of 64 sensors that adds up data from the rows and columns, a step toward meeting NASA requirements.
“My primary motivation for making the camera is NASA’s Origins Space Telescope project, which is looking into using these arrays for analyzing the chemical composition of planets orbiting stars outside of our solar system,” NIST electronics engineer Varun Verma explains. Each chemical element in the planet’s atmosphere would absorb a unique set of colors, he points out.
The new camera was made at NIST’s Microfabrication Facility in Boulder, Colorado. The work was supported by both NASA and the Defense Advanced Research Projects Agency (DARPA).
NIST researcher Varun Verma explains how a new NIST camera, made of nanometer-scale wires, could efficiently capture light from atmospheres of extrasolar planets that possibly harbor life. Go to this video at:
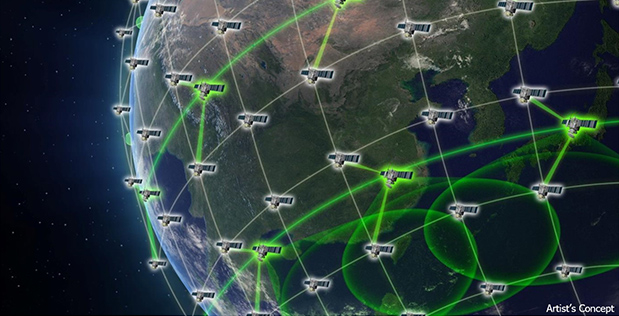
Self-knowing satellites make up the Blackjack constellation.
Credit: DARPA
Pit Boss is an autonomous mission management system for the Defense Advanced Research Projects Agency’s (DARPA) Blackjack satellite constellation.
DARPA’s Blackjack constellation is designed to operate in low Earth orbit. It will network sensors together with a goal to provide persistent global coverage for many applications, including missile warning.
Raytheon is designing Pit Boss that connects the brains of each Blackjack satellite to establish an exceptionally smart, networked system.
AI, machine learning
According to Raytheon, Pit Boss aims to use an advanced architecture, processors and encryption to autonomously collect and process data from the entire Blackjack constellation. It is also envisioned to be able to incorporate future advanced algorithms, including artificial intelligence and machine learning.
Pit Boss is the data collection and processing data hub. By fusing the sensor data together, decision-making speeds up, transitioning from what is known as operator-in-the-loop to operator-on-the-loop methodology.
Rather than sending data down to a ground station for processing, which takes time, Pit Boss will send data from space straight to the right operator at the right time.
CASINO
“Self-knowing satellites are the next step in autonomous space-based mission planning,” said Mike Rokaw, director for Raytheon Space Systems. “And, this isn’t limited to missile warning and defense. Future constellation management systems will migrate to this type of methodology.”
Given Blackjack’s success, the plan is for the Air Force’s Space and Missile Systems Center (SMC) to transition the architecture to a program tagged Commercially Augmented Space Inter Networked Operations – or CASINO for short.
For more information, go to this DARPA info at:
https://www.darpa.mil/program/blackjack

Curiosity now has another butte in view: “Western butte”
Curiosity Left B Navigation Camera image acquired on Sol 2589, November 18, 2019.
Credit: NASA/JPL-Caltech
NASA’s Curiosity Mars Rover is now performing Sol 2589 tasks.
Reports Roger Wiens, noted geochemist at Los Alamos National Laboratory:
“After the ‘butte-iful’ location and view of sols 2585-2586, Curiosity descended back down from its perch on ‘Central butte’ and skirted its steep side,” Wiens explains.

Curiosity Front Hazard Avoidance Camera Right B photo taken on Sol 2589, November 18, 2019.
Credit: NASA/JPL-Caltech
The robot now has another butte in view, “Western butte.”
“Little by little, Curiosity is climbing higher, toward the edge of ‘Greenheugh pediment,’”Wiens adds.

Curiosity Left B Navigation Camera image acquired on Sol 2589, November 18, 2019.
Credit: NASA/JPL-Caltech
New location
The drive of Curiosity was 131 feet (40 meters) toward the southwest. At the new location, Curiosity will observe two targets, “Blawhorn” and “Gorgie,” with Mastcam, Chemistry and Camera (ChemCam), the Mars Hand Lens Imager (MAHLI), and its Alpha Particle X-Ray Spectrometer (APXS).
Mastcam will also take images of “Yella Moor,” “Dalchork,” “Glen Lui,” and “Craigmillar,” as well as making a tau measurement and a crater rim extinction observation, Wiens points out.

Curiosity Left B Navigation Camera image acquired on Sol 2589, November 18, 2019.
Credit: NASA/JPL-Caltech
Sky survey
MAHLI will take an image of the Rover Environmental Monitoring Station (REMS) UV sensor. Navcam will take dust-devil movies, suprahorizon movies, and a 360 sky survey.
REMS, Radiation Assessment Detector (RAD), and the Dynamic Albedo of Neutrons (DAN) will also take data.
On the final day of the weekend plan, Curiosity was to advance 66 feet (20 meters), after which it will take Navcam images of its new surroundings. The rover will then compute a ChemCam target, using the Autonomous Exploration for Gathering of Increased Science (AEGIS) software, which will then direct the instrument to shoot a 3×3 raster on it.

Credit: NASA/JPL-Caltech/Univ. of Arizona
“Finally, Mastcam will take a sunset tau observation, and the rover will radio home with a large bundle of new data,” Wiens concludes.
New road map
Meanwhile, a new map has been issued showing Curiosity’s location for Sol 2589.

Credit: NASA/JPL-Caltech/Univ. of Arizona
The map shows the route driven by NASA’s Mars rover Curiosity through the 2589 Martian day, or sol, of the rover’s mission on Mars (November 18, 2019).
Numbering of the dots along the line indicate the sol number of each drive. North is up.
From Sol 2586 to Sol 2589, Curiosity had driven a straight line distance of about 23.85 feet (7.27 meters). Since touching down in Bradbury Landing in August 2012, Curiosity has driven 13.27 miles (21.36 kilometers).
The base image from the map is from the High Resolution Imaging Science Experiment Camera (HiRISE) in NASA’s Mars Reconnaissance Orbiter.

Curiosity Mars Hand Lens Imager (MAHLI) photo produced on Sol 2587, November 16, 2019.
Credit: NASA/JPL-Caltech/MSSS

Curiosity Right B Navigation Camera photo taken on Sol 2589, November 18, 2019.
Credit: NASA/JPL-Caltech

Curiosity Right B Navigation Camera image acquired on Sol 2588, November 17, 2019.
Credit: NASA/JPL-Caltech

See You In Orbit? – Our Dream Of Spaceflight by Alan Ladwig, To Orbit Productions, LLC, October 2019; paperback, 500 pages, $18.00.
Public space travel is soon getting a boost from Richard Branson’s Virgin Galactic and the efforts of the Jeff Bezos-backed Blue Origin. Plunking down cash to skyrocket into near-space heights and escape velocity vacationing in Earth orbit is in the offing. Or is it?
Strap in, place your table trays into locked position and enjoy a highly revealing read from author Alan Ladwig, a former manager of both the Shuttle Student Involvement Program and the Spaceflight Participant Program, which included the Teacher in Space and Journalist in Space competitions.
See You in Orbit? is a superb, fact-filled account of the on-going promise of commercial space tourism, and pulls no punches about why it has been such a long, drawn-out countdown to reality.
Ladwig at the outset of the volume admits the book has been “a crime of passion for over three decades.” The reader will be consumed by that zeal contained within 13 chapters that begins with the dreams of yesterday and concludes with wagons ho and way beyond Earth’s boundaries. Within that sweep of reading, I myself was drawn to the author’s behind-the-scenes account of the loss of Challenger and its crew that included teacher-in-space, Christa McAuliffe – subtitled “The Dream Turns into Heartbreak.”

Footloose and fancy-free, author Alan Ladwig.
Credit: To Orbit Productions
Ladwig has an engaging, witty, and often poignant writing manner that adds to the reader’s page-turning experience. The author is no stranger to zero-gravity, having experienced hundreds of parabolas on ZERO-G’s G-Force 1 and NASA’s KC-135. That said, he confesses that the thought of being confined in a small capsule gives him the willies. “Trust me, you wouldn’t want me sitting in the middle seat next to you,” he writes.
The book includes an extensive chapter-by-chapter notes section, clearly demonstrating the author’s exhaustive research in writing this enlightening and instructive volume.
Be it “The Scent of Musk” or “Space Cycler Built for Two” or “How Many Billionaires Does It Take to Get Us to Space?”…these and other quips guide the reader to a wisdom-filled smooth touchdown.
For more information on this book, go to:
https://www.amazon.com/See-You-Orbit-Dream-Spaceflight/dp/1733265708
Remarks by Vice President Pence to NASA’s Ames Research Center Employees and Guests | Moffett Field, CA
Issued on: November 14, 2019
Go to:

Vice President Mike Pence (right) gets a look at an engineering test unit for VIPER – short for Volatiles Investigating Polar Exploration Rover – a lunar rover capable of seeking out water ice in the Moon’s soil, at NASA’s Ames Research Center in California’s Silicon Valley on Nov. 14, 2019. VIPER project scientist Anthony Colaprete (left) and VIPER project manager and Ames’ director of engineering Daniel Andrews (center) explained how the prospecting rover, launching in 2022, will map out the location and concentration of water ice at the Moon’s south pole, ahead of the first Artemis astronauts’ arrival in 2024.
Credit: NASA/Dominic Hart
During his visit to Ames, the vice president took a tour of the center that featured highlights of facilities and projects critical to the Artemis program. These included the Vertical Motion Simulator, the world’s largest flight simulator, which could also help prepare the next astronauts to land on the Moon; the Arc Jet Complex, NASA’s high-energy wind tunnel for testing materials and designs that protect spacecraft from intense heating when entering an atmosphere; and the VIPER lunar rover mission.

Vice President Mike Pence (left) and NASA Administrator Jim Bridenstine (right) in the Vertical Motion Simulator at NASA’s Ames Research Center in Silicon Valley.
Credits: Photo by official White House photographer Myles Cullen
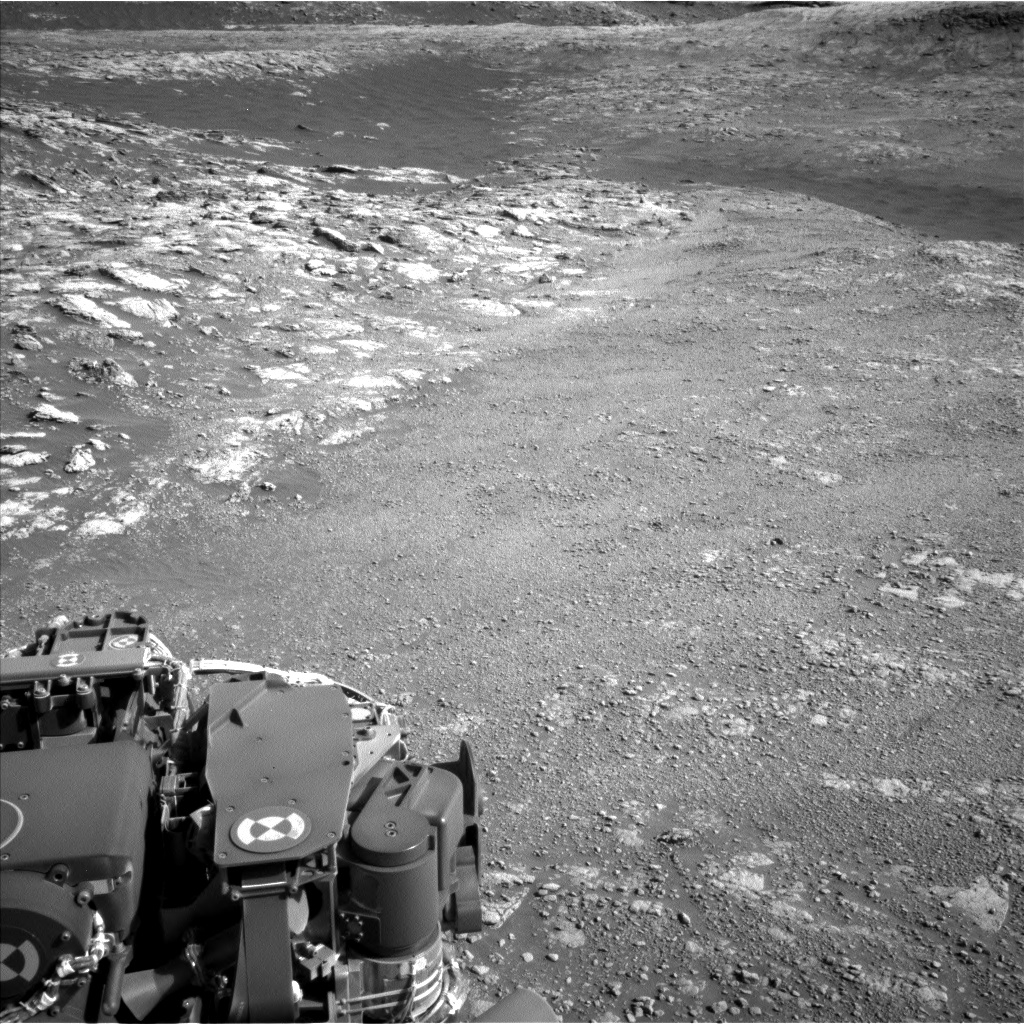
Curiosity Navigation Left B Camera image acquired on Sol 2586, November 15, 2019.
Credit: NASA/JPL-Caltech
NASA’s Curiosity Mars rover is now closing out Sol 2586 science duties.
Reports Claire Newman, an atmospheric scientist at Aeolis Research, Curiosity is again at the “Hunda” facies, high up on Central Butte.
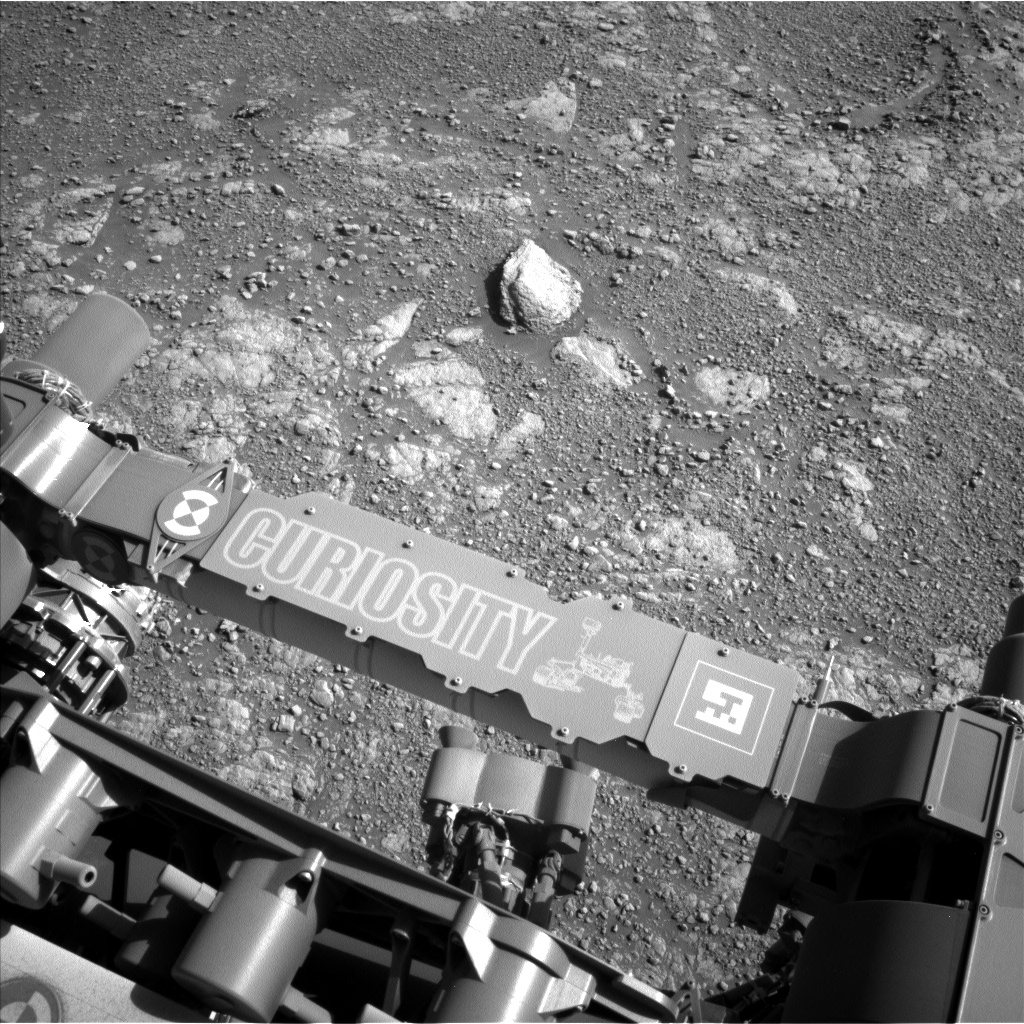
Curiosity Navigation Left B Camera image acquired on Sol 2586, November 15, 2019.
Credit: NASA/JPL-Caltech
“At this location, we’re finding a lot of decimeter-scale laminations – sequences of fine layers – near to and underneath the rover,” Newman explains.
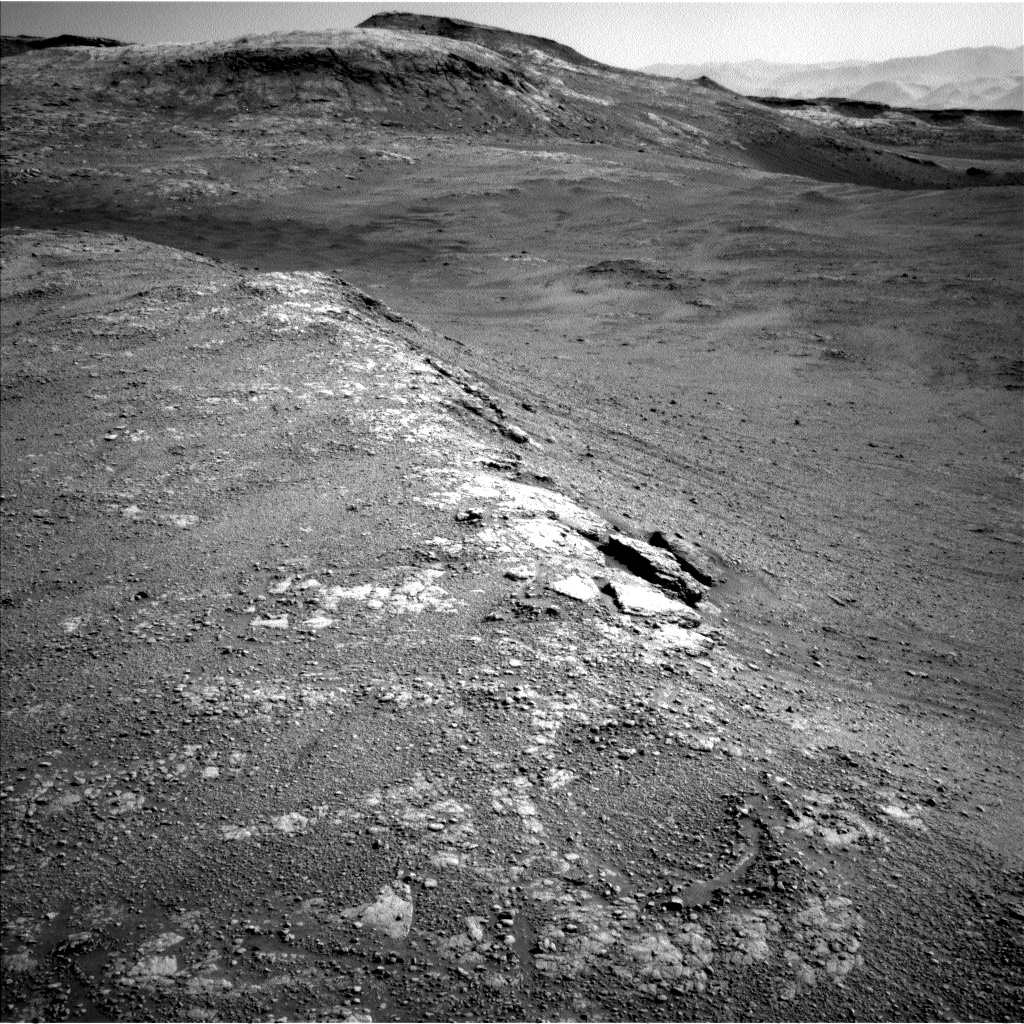
Curiosity Navigation Left B Camera image acquired on Sol 2586, November 15, 2019.
Credit: NASA/JPL-Caltech
Float rock
In these layers, target “Kirkcudbrightshire” was chosen as the location for first Chemistry and Camera (ChemCam) then Alpha Particle X-Ray Spectrometer (APXS) analysis, the idea being that ChemCam Laser Induced Breakdown Spectrometer (LIBS) would remove any dust covering the target before the APXS contact science overnight.
A second APXS target “Foggy Moss” was chosen to sample the float rock found here, which was already analyzed using ChemCam in a prior sol.
“Here ‘float’ refers to the piece of rock having been transported from its original outcrop, and this one might represent the cap rock of the entire butte,” Newman adds.
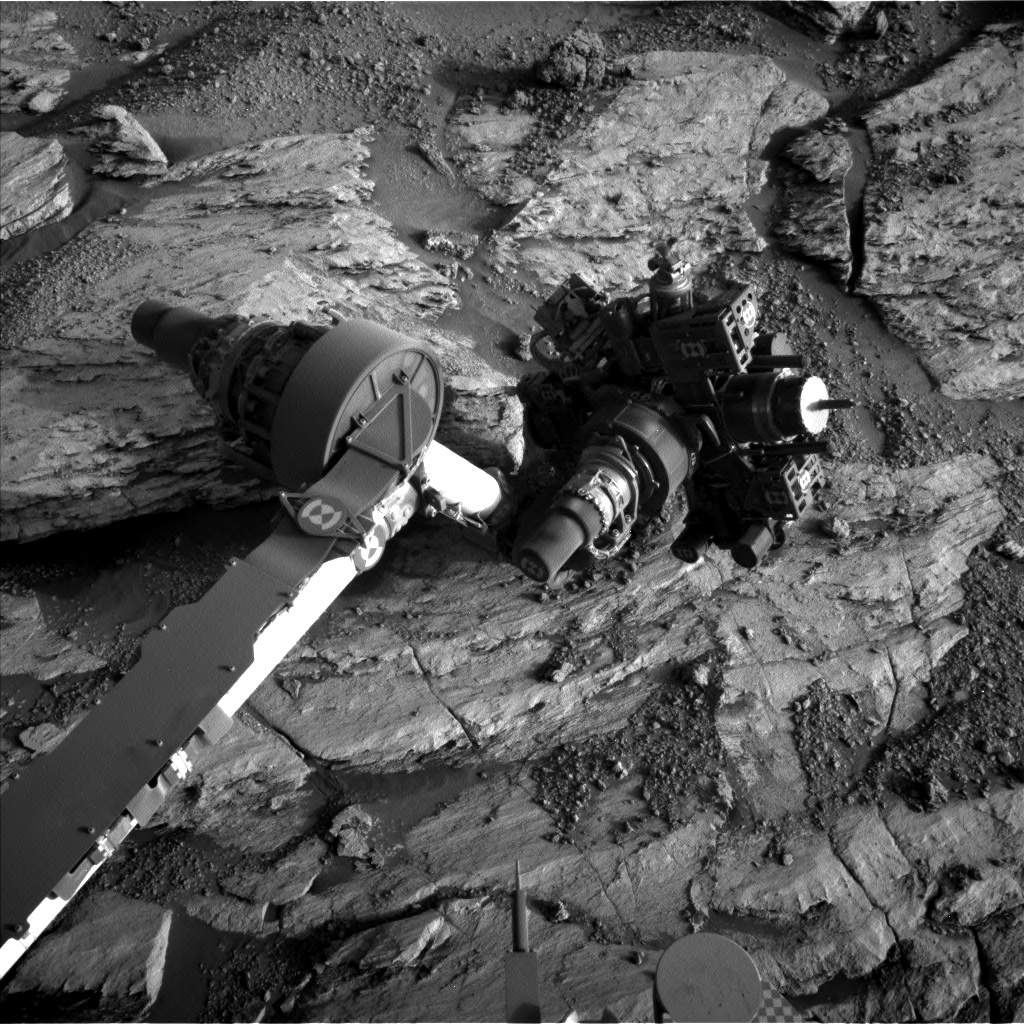
Curiosity Navigation Camera Left B photo taken on Sol 2585, November 14, 2019.
Credit: NASA/JPL-Caltech
Edge of rock ledge
More ChemCam LIBS analyses were planned on targets “Kincardineshire,” which may sample the edge of the rock ledge, “Grogsport,” another bedrock target higher in the section (to test how chemistry, especially sulfate content, changes with position), and “Hog Burn,” another float rock which might also represent the capping unit and can be compared with Foggy Moss, Newman points out.
Mastcam mosaics and ChemCam documentation images, Newman continues, were used to place all of these measurements in context, and the geology side of the plan finished with Mastcam stereo of layers in the outcrop (“Bonny Braes”), as well as a Mastcam context mosaic of additional outcrop, allowing the various mosaics from this location to be linked together (“Bonnie View”).
Dog’s eye mosaic
Also planned are Mars Hand Lens Imager (MAHLI) images of Kirkcudbrightshire and Foggy Moss, and a MAHLI ‘dog’s eye’ mosaic of target “Sourhope”; the latter means that the arm will be positioned so MAHLI looks sideways (rather than down) at the target, Newman notes, to get a better view of the laminations within the rocks.
On the environmental side of the plan, Mars rover scientists included the usual Rover Environmental Monitoring Station (REMS) monitoring of atmospheric and surface temperature, surface pressure, humidity, and UV radiation, plus Dynamic Albedo of Neutrons (DAN) passive and active monitoring of the subsurface composition, and the ongoing continuous Radiation Assessment Detector (RAD) monitoring of energetic particle radiation.

Curiosity Mars Hand Lens Imager (MAHLI) photo produced on Sol 2583, November 12, 2019.
Credit: NASA/JPL-Caltech/MSSS
Cloud altitude, dust devils
“We’re in the cloudy season right now, so we added in a Navcam Cloud Altitude Observation which uses observations of clouds and their shadows, plus geometry, to work out cloud heights,” Newman reports. “This is a valuable piece of information for inferring the vertical structure of the crater’s atmosphere, as cloud height is related to both water abundance and the thermal profile.”
Also added to planning is a Navcam Dust Devil Survey at about 4:20pm local true solar time. “This is a few hours later than we expect most dust devils to occur, especially in winter, based on both theory and past observations,” Newman observes.
“However, we’ve observed dust devils this late in the day in other seasons, and it’s important to repeat these surveys at a range of times in every season each year, rather than assuming nothing will change as we move up the slope! Finally, we measured the amount of dust above us and the visibility across the crater at two times of sol using Mastcam, and measured the across-crater visibility at one time of sol with Navcam also,” Newman concludes.
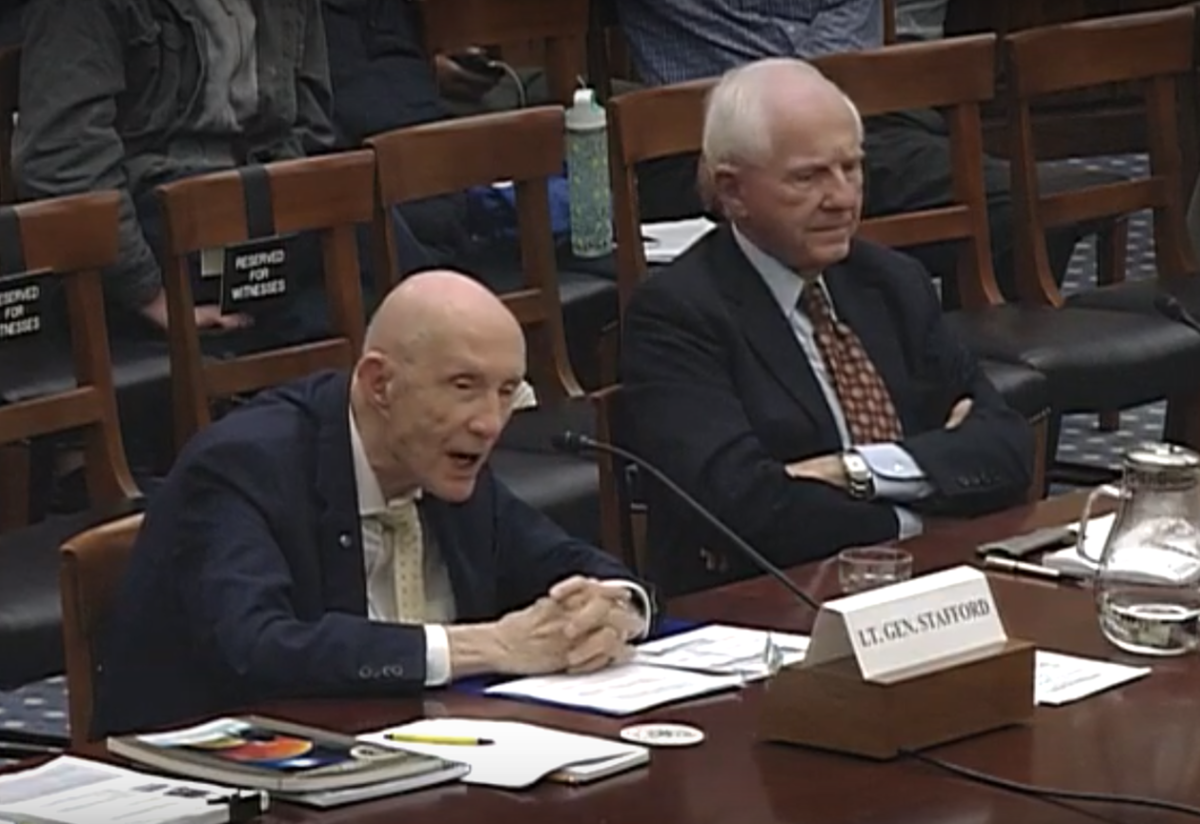
Lt. General Thomas P. Stafford and Mr. A. Thomas Young
Credit: Subcommittee on Space and Aeronautics/Screengrab Inside Outer Space
SUBCOMMITTEE ON SPACE AND AERONAUTICS
DATE: WEDNESDAY, NOVEMBER 13, 2019
TIME: 02:00 PM
LOCATION: 2318 RAYBURN HOUSE OFFICE BUILDING
OPENING STATEMENTS:
Chair Kendra Horn (D-OK) of the Subcommittee on Space and Aeronautics
https://science.house.gov/imo/media/doc/11.13.19%20CHorn%20OS%20Sights%20on%20Mars%20.pdf
Chairwoman Eddie Bernice Johnson (D-TX)
https://science.house.gov/imo/media/doc/11.13.19%20CJohnson%20OS%20Sights%20on%20Mars%20.pdf

Credit: NASA
Credit: NASA
— Lt. General Thomas P. Stafford, USAF (Ret.); Member, National Academy of Engineering; Chairman, NASA ISS Advisory Committee; Pilot, Gemini 6, Commander, Gemini 9; Cdr. Apollo 10, Cdr. Apollo/Apollo-Soyuz Test Program; Former USAF Deputy Chief of Staff for Research, Development and Acquisition
https://science.house.gov/imo/media/doc/Stafford%20Testimony%20.pdf
— Mr. A. Thomas Young, Former Director of NASA Goddard Space Flight Center, Former President and Chief Operating Officer Martin Marietta Corp
https://science.house.gov/imo/media/doc/Young%20Testimony1.pdf
To view the hearing, go to this video at:

